1 悬臂梁平面问题题目

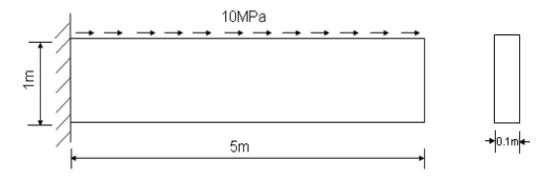
图1.1 悬臂梁示意图

图1.1 悬臂梁示意图

  已知:悬臂梁的材料参数为E=190GPaE=190GPa,μ=0.25\mu=0.25,t=10cmt=10cm,ρ=0\rho=0。尺寸参数如图。

  要求:

  (1)单元数量从少到多自行选择3组计算对比结果(与解析解对比计算精度)。

  (2)采用三角形三结点单元(题目可以看做是平面应力问题),用程序计算求解。

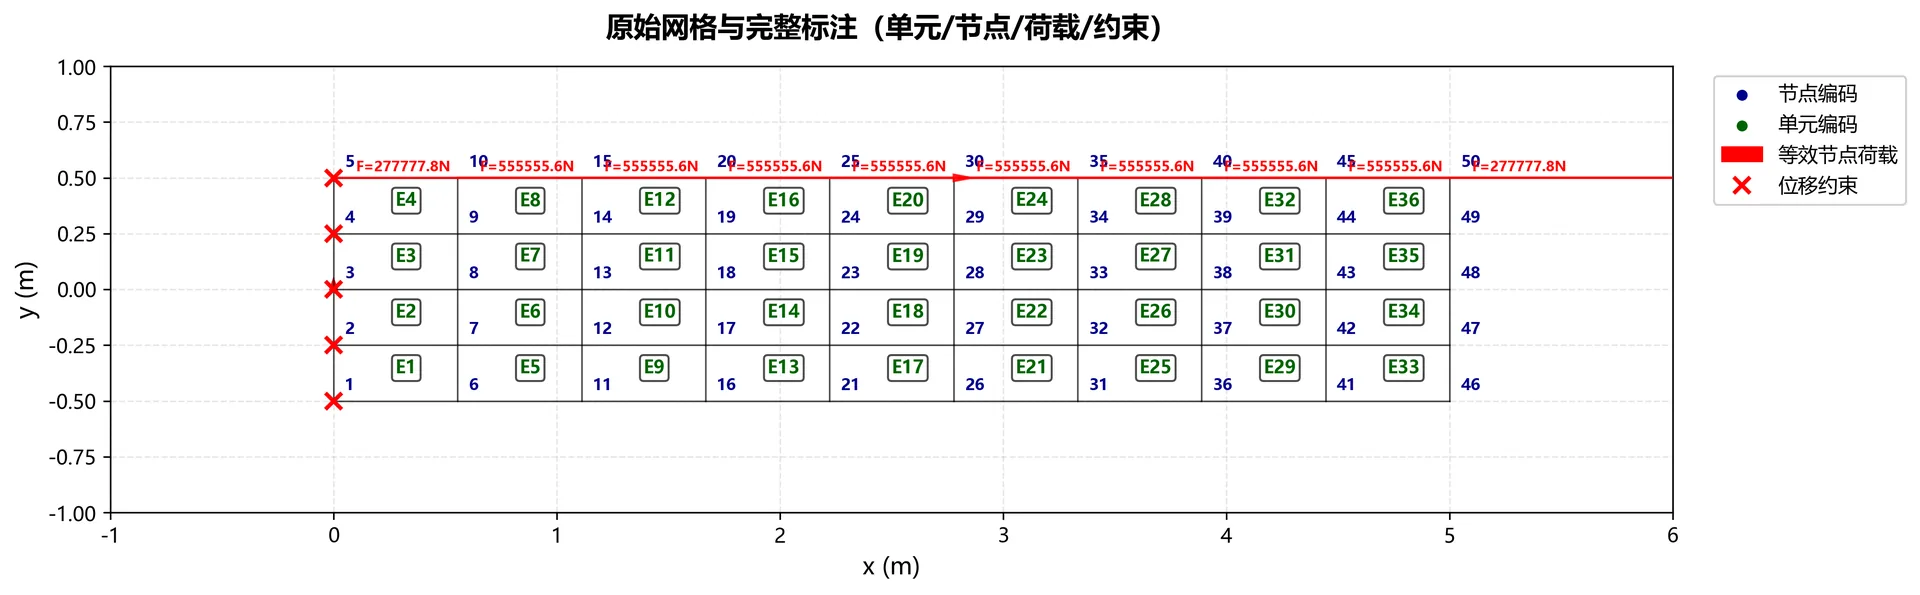
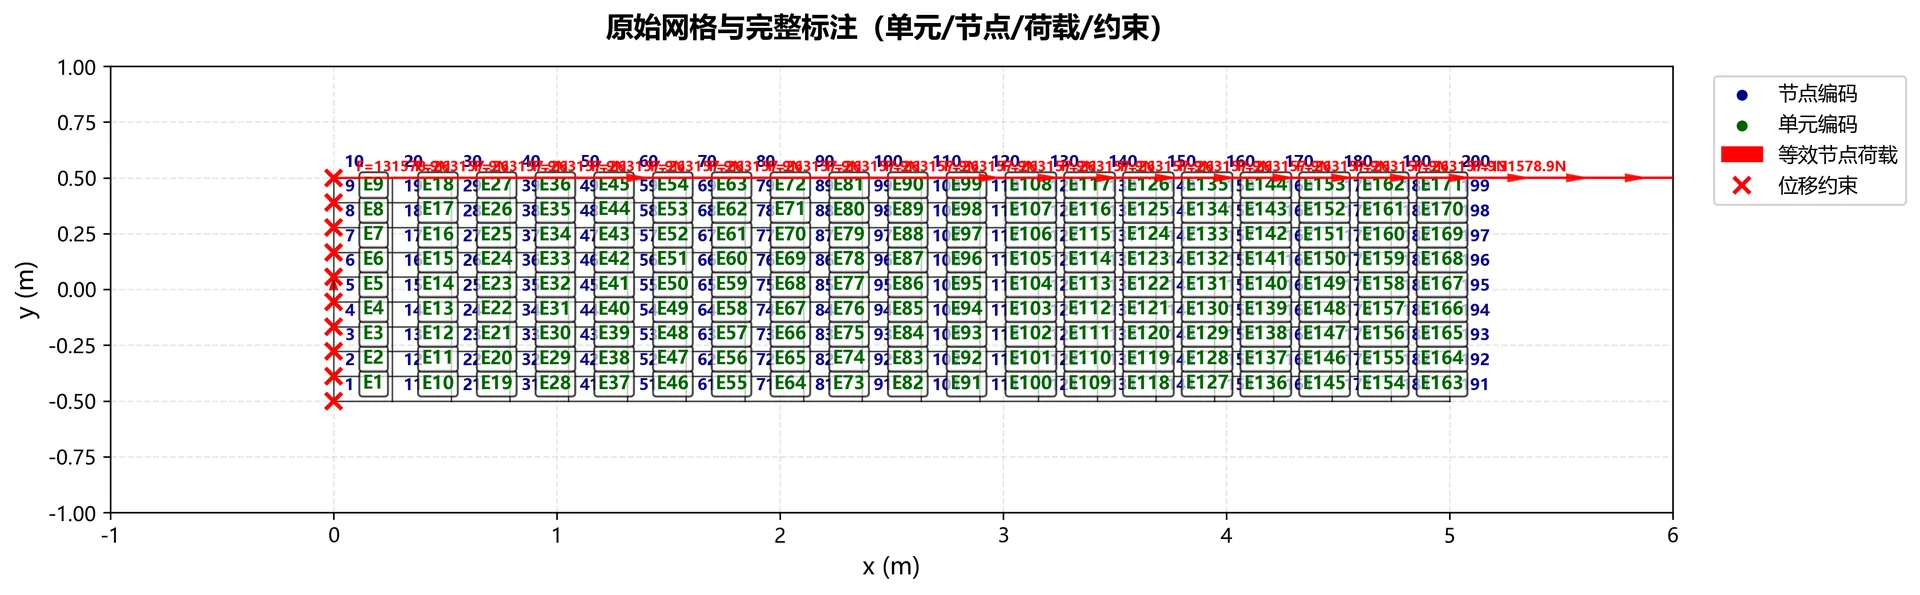
  (3)对应选择的每一组单元数量形式,画出力学模型图(包括单元的划分、结点编码、等效结点荷载、位移约束等信息)。

  (4)写出输入数据和输出数据(位移、应力)。

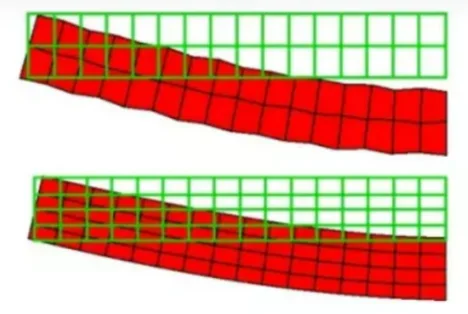
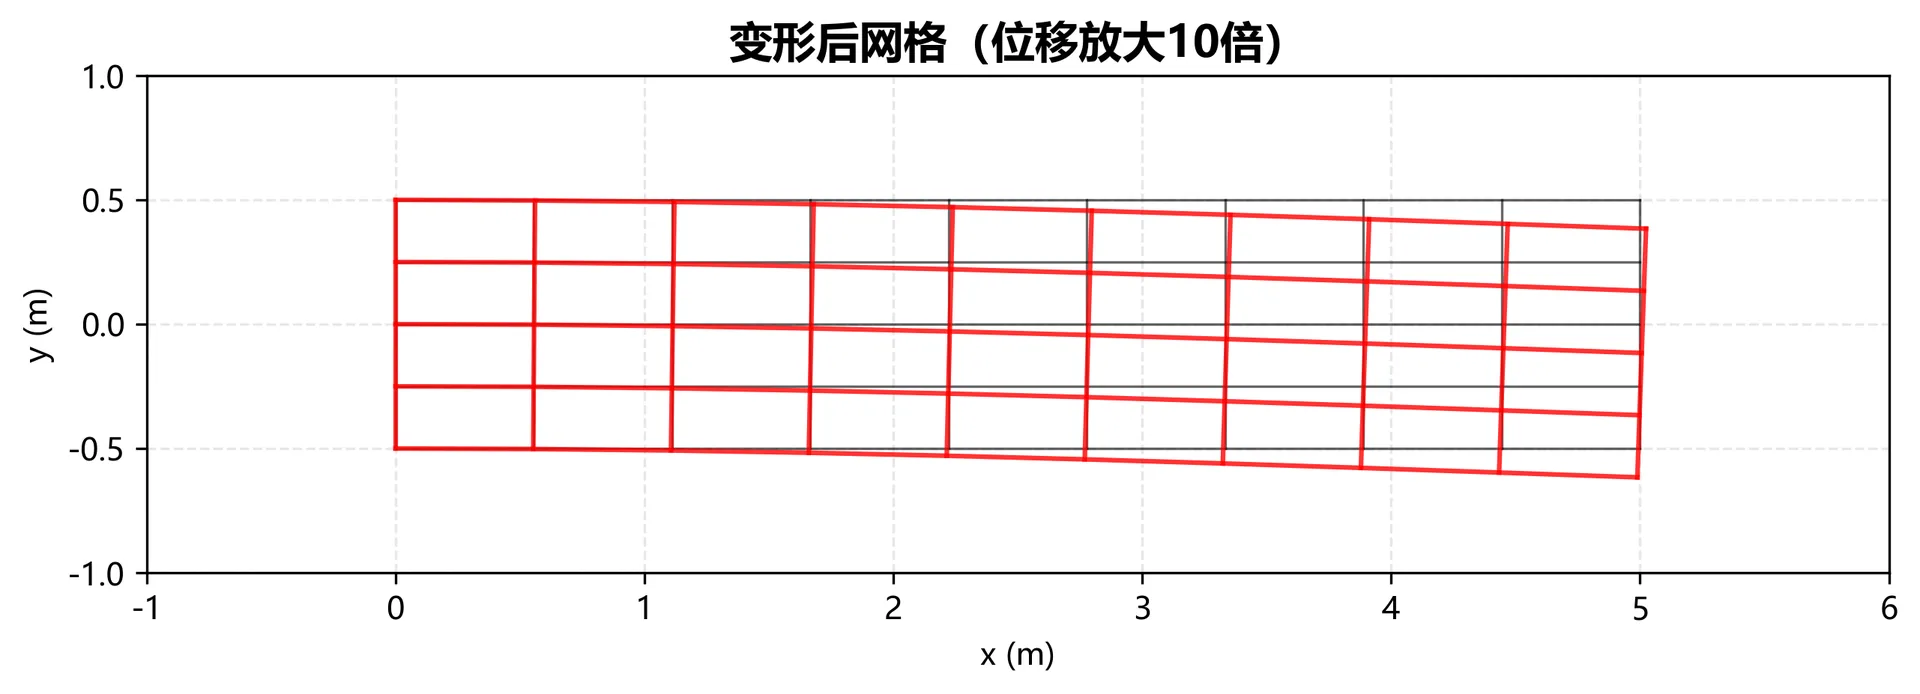
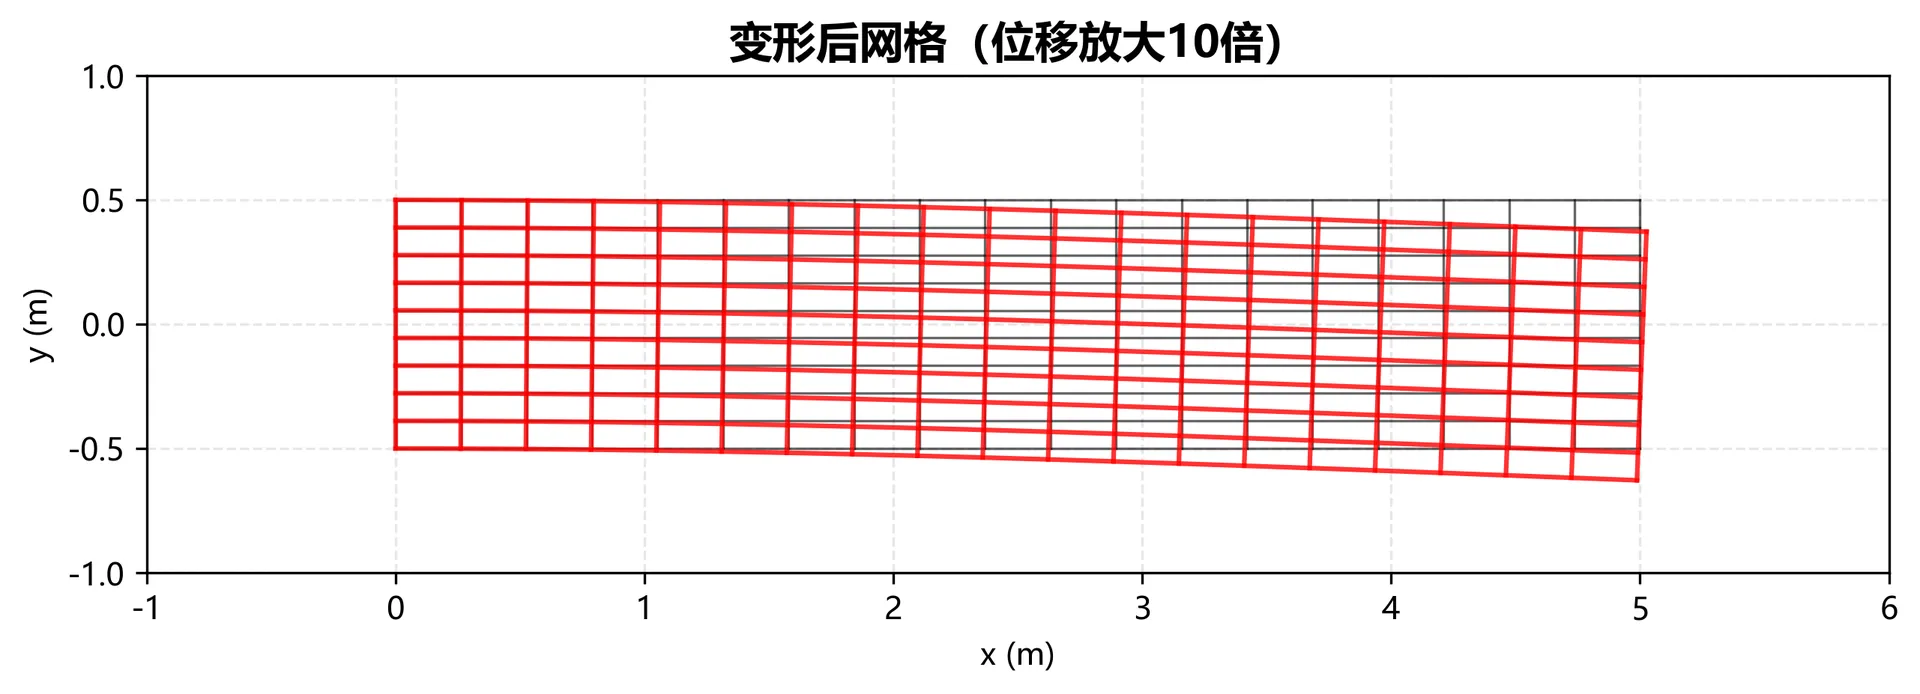
  (5)画出如下图形式的变形网格图。

图1.2 变形网格示意图

图1.2 变形网格示意图

2 Python源程序

  **本文中使用的Python版本是3.14.3(64-bit)。**源程序已上传 GitHub:四结点四边形单元。

  两个程序(四结点四边形单元、三结点三角形单元)结构完全一致,都是标准的有限元流程:

段落 作用
1 导入依赖库 numpy 用于矩阵运算与线性方程组求解,matplotlib 用于绘制网格与云图
2 全局配置 几何、材料、数值计算参数,以及基于这些参数推导的理论解
3 输入处理工具函数 参数读取与校验
4 单元核心计算函数 形函数、雅可比矩阵、BB 矩阵、单元刚度矩阵、应力计算
5 可视化函数 绘制网格划分、节点与单元编号、等效节点荷载、位移约束、云图
6 主分析流程 生成网格 → 组装总刚与荷载向量 → 施加边界条件 → 求解 → 提取位移与应力 → 误差分析
7 程序入口 组织并调用上述流程

2.1 四结点四边形单元有限元Python程序

  源代码已上传github,详见链接。

1
2
3
4
5
6
7
8
9
10
11
12
13
14
15
16
17
18
19
20
21
22
23
24
25
26
27
28
29
30
31
32
33
34
35
36
37
38
39
40
41
42
43
44
45
46
47
48
49
50
51
52
53
54
55
56
57
58
59
60
61
62
63
64
65
66
67
68
69
70
71
72
73
74
75
76
77
78
79
80
81
82
83
84
85
86
87
88
89
90
91
92
93
94
95
96
97
98
99
100
101
102
103
104
105
106
107
108
109
110
111
112
113
114
115
116
117
118
119
120
121
122
123
124
125
126
127
128
129
130
131
132
133
134
135
136
137
138
139
140
141
142
143
144
145
146
147
148
149
150
151
152
153
154
155
156
157
158
159
160
161
162
163
164
165
166
167
168
169
170
171
172
173
174
175
176
177
178
179
180
181
182
183
184
185
186
187
188
189
190
191
192
193
194
195
196
197
198
199
200
201
202
203
204
205
206
207
208
209
210
211
212
213
214
215
216
217
218
219
220
221
222
223
224
225
226
227
228
229
230
231
232
233
234
235
236
237
238
239
240
241
242
243
244
245
246
247
248
249
250
251
252
253
254
255
256
257
258
259
260
261
262
263
264
265
266
267
268
269
270
271
272
273
274
275
276
277
278
279
280
281
282
283
284
285
286
287
288
289
290
291
292
293
294
295
296
297
298
299
300
301
302
303
304
305
306
307
308
309
310
311
312
313
314
315
316
317
318
319
320
321
322
323
324
325
326
327
328
329
330
331
332
333
334
335
336
337
338
339
340
341
342
343
344
345
346
347
348
349
350
351
352
353
354
355
356
357
358
359
360
361
362
363
364
365
366
367
368
369
370
371
372
373
374
375
376
377
378
379
380
381
382
383
384
385
386
387
388
389
390
391
392
393
394
395
396
397
398
399
400
401
402
403
404
405
406
407
408
409
410
411
412
413
414
415
416
417
418
419
420
421
422
423
424
425
426
427
428
429
430
431
432
433
434
435
436
437
438
439
440
441
442
443
444
445
446
447
448
449
450
451
452
453
454
455
456
457
458
459
460
461
462
463
464
465
466
467
468
469
470
471
472
473
474
475
476
477
478
479
480
481
482
483
484
485
486
487
488
489
490
491
492
493
494
495
496
497
498
499
500
501
502
503
504
505
506
507
508
509
510
511
512
513
514
515
516
517
518
519
520
521
522
523
524
525
526
527
528
529
530
531
532
533
534
535
536
537
538
539
540
541
542
543
544
545
546
547
548
549
550
551
552
553
554
555
556
557
558
559
560
561
562
563
564
565
566
567
568
569
570
571
572
573
574
575
576
577
578
579
580
581
582
583
584
585
586
587
588
589
590
591
592
593
594
595
596
597
598
599
600
601
602
603
604
605
606
607
608
609
610
611
612
613
614
615
616
617
618
619
620
621
622
623
624
625
626
627
628
629
630
631
632
633
634
635
636
637
638
639
640
641
642
643
644
645
646
647
648
649
650
651
652
653
654
655
656
657
658
659
660
661
662
663
664
665
666
667
668
669
670
671
672
673
674
675
676
677
678
679
680
681
682
683
684
685
686
687
688
689
690
691
"""
等截面悬臂梁平面应力有限元分析程序(四结点四边形单元版 v2.4.1)

核心功能:
1. 基于四节点四边形等参单元实现悬臂梁平面应力有限元全流程分析
2. 优化位移计算精度(自由端中点插值、高精度荷载积分)
3. 生成6张高清可视化图片
"""


# ===================== 1. 导入依赖库 =====================
import traceback
from typing import Tuple, Dict, Any

import numpy as np
import matplotlib.pyplot as plt
import matplotlib
from numpy.polynomial.legendre import leggauss
from scipy.interpolate import interp1d


# ===================== 2. 全局配置 =====================
# 绘图配置
matplotlib.rcParams['font.sans-serif'] = ['Microsoft YaHei', 'SimHei', 'PingFang SC']
matplotlib.rcParams['axes.unicode_minus'] = False
matplotlib.rcParams['figure.dpi'] = 120
matplotlib.rcParams['savefig.dpi'] = 300

# 几何参数(与理论解严格匹配)
BEAM_LENGTH = 5.0 # 梁总长 (m)
BEAM_HEIGHT = 1.0 # 梁截面高度 (m)
BEAM_THICKNESS = 0.1 # 梁厚度(平面应力)(m)

# 材料参数
ELASTIC_MODULUS = 190e9 # 弹性模量 (Pa)
POISSON_RATIO = 0.25 # 泊松比
APPLIED_SHEAR_STRESS = 10e6 # 顶部剪应力 (Pa)

# 理论解(基于上述参数推导)
THEORY_DISP_X = 0.00131578947368 # 自由端水平位移 (m)
THEORY_DISP_Y = -0.0130921052632 # 自由端竖向位移 (m)

# 数值计算参数
GAUSS_ORDER = 2 # 2×2高斯积分(4节点单元最优)
TINY_VALUE = 1e-15 # 数值稳定性极小值
FLOAT_TYPE = np.float64 # 双精度浮点类型
DISP_SCALE_FACTOR = 10 # 位移放大因子


# ===================== 3. 输入处理工具函数 =====================
def get_valid_integer_input(prompt: str, min_value: int = 2) -> int:
"""
获取用户输入的有效正整数,包含输入合法性验证

Args:
prompt: 输入提示文本
min_value: 输入最小值(默认2,保证至少1个单元)

Returns:
验证通过的正整数
"""
while True:
try:
user_input = int(input(prompt))
if user_input >= min_value:
return user_input
print(f"错误:数值必须≥{min_value},请重新输入")
except ValueError:
print("错误:请输入有效正整数(如5、10、20)")


# ===================== 4. 四边形单元核心计算函数 =====================
def quad4_shape_functions(s: float, t: float) -> np.ndarray:
"""计算4节点四边形等参单元形函数值(自然坐标[-1,1])"""
n1 = (1 - s) * (1 - t) / 4.0
n2 = (1 + s) * (1 - t) / 4.0
n3 = (1 + s) * (1 + t) / 4.0
n4 = (1 - s) * (1 + t) / 4.0
return np.array([n1, n2, n3, n4], dtype=FLOAT_TYPE)

def quad4_shape_derivatives(s: float, t: float) -> Tuple[np.ndarray, np.ndarray]:
"""计算4节点四边形单元形函数对自然坐标的偏导数"""
dN_ds = np.array([
-(1 - t)/4.0, (1 - t)/4.0,
(1 + t)/4.0, -(1 + t)/4.0
], dtype=FLOAT_TYPE)

dN_dt = np.array([
-(1 - s)/4.0, -(1 + s)/4.0,
(1 + s)/4.0, (1 - s)/4.0
], dtype=FLOAT_TYPE)

return dN_ds, dN_dt

def calculate_jacobian(
dN_ds: np.ndarray,
dN_dt: np.ndarray,
elem_x: np.ndarray,
elem_y: np.ndarray
) -> Tuple[np.ndarray, float, np.ndarray]:
"""计算雅可比矩阵、行列式及逆矩阵(自然坐标→物理坐标转换)"""
jac = np.zeros((2, 2), dtype=FLOAT_TYPE)
for i in range(4):
jac[0, 0] += dN_ds[i] * elem_x[i] # ∂x/∂s
jac[0, 1] += dN_ds[i] * elem_y[i] # ∂y/∂s
jac[1, 0] += dN_dt[i] * elem_x[i] # ∂x/∂t
jac[1, 1] += dN_dt[i] * elem_y[i] # ∂y/∂t

det_jac = jac[0,0]*jac[1,1] - jac[0,1]*jac[1,0]
if abs(det_jac) < TINY_VALUE:
raise ValueError(f"雅可比行列式过小({det_jac:.2e}),数值不稳定")

inv_jac = np.array([
[jac[1,1]/det_jac, -jac[0,1]/det_jac],
[-jac[1,0]/det_jac, jac[0,0]/det_jac]
], dtype=FLOAT_TYPE)

return jac, det_jac, inv_jac

def calculate_B_matrix(dN_dx: np.ndarray, dN_dy: np.ndarray) -> np.ndarray:
"""计算平面应力问题的应变-位移矩阵B(ε = B·u)"""
B = np.zeros((3, 8), dtype=FLOAT_TYPE)
for i in range(4):
u_idx = 2 * i
v_idx = 2 * i + 1
B[0, u_idx] = dN_dx[i] # ε_xx = ∂u/∂x
B[1, v_idx] = dN_dy[i] # ε_yy = ∂v/∂y
B[2, u_idx] = dN_dy[i] # γ_xy = ∂u/∂y + ∂v/∂x
B[2, v_idx] = dN_dx[i]
return B

def calculate_surface_load(
elem_x: np.ndarray,
elem_y: np.ndarray,
stress: float,
thickness: float
) -> np.ndarray:
"""基于形函数积分计算面荷载的等效节点荷载(高精度)"""
gauss_pts, gauss_wts = leggauss(2)
elem_load = np.zeros(8, dtype=FLOAT_TYPE)

for i, s in enumerate(gauss_pts):
t = 1.0 # 顶部边自然坐标t=1
weight = gauss_wts[i]

N = quad4_shape_functions(s, t)
dN_ds, _ = quad4_shape_derivatives(s, t)

dx_ds = np.sum(dN_ds * elem_x)
dy_ds = np.sum(dN_ds * elem_y)
ds = np.sqrt(dx_ds**2 + dy_ds**2)

for j in range(4):
elem_load[2*j] += N[j] * stress * thickness * ds * weight

return elem_load

def get_free_end_mid_disp(
disp: np.ndarray,
node_x: np.ndarray,
node_y: np.ndarray
) -> Tuple[float, float]:
"""精准提取自由端(x=梁长)几何中点的位移(适配奇偶节点数)"""
nx, ny = node_x.shape
free_end_idx = []
free_end_y = []
free_end_dx = []
free_end_dy = []

for j in range(ny):
global_idx = (nx-1)*ny + j
if abs(node_x[nx-1, j] - BEAM_LENGTH) < TINY_VALUE:
free_end_idx.append(global_idx)
free_end_y.append(node_y[nx-1, j])
free_end_dx.append(disp[2*global_idx, 0])
free_end_dy.append(disp[2*global_idx+1, 0])

free_end_y = np.array(free_end_y, dtype=FLOAT_TYPE)
mid_y = (free_end_y.min() + free_end_y.max()) / 2.0

interp_dx = interp1d(free_end_y, free_end_dx, kind='linear', fill_value="extrapolate")
interp_dy = interp1d(free_end_y, free_end_dy, kind='linear', fill_value="extrapolate")

return float(interp_dx(mid_y)), float(interp_dy(mid_y))

def print_result_compare(theory: Dict[str, float], fem: Dict[str, float]) -> None:
"""格式化打印有限元解与理论解的对比表格"""
print("\n" + "="*85)
print("有限元解与理论解对比表")
print("="*85)
print(f"{'分析项目':<25} {'理论解':<20} {'有限元解':<20} {'相对误差(%)':<15}")
print("-"*85)

for item in theory.keys():
t_val = theory[item]
f_val = fem[item]
err = abs((f_val - t_val)/t_val)*100 if abs(t_val) > TINY_VALUE else 100.0
print(f"{item:<25} {t_val:<20.8e} {f_val:<20.8e} {err:<15.4f}")

print("="*85)


# ===================== 5. 可视化函数 =====================
def save_mesh_plot_with_annotations(
node_x: np.ndarray,
node_y: np.ndarray,
top_nodes: list,
elem_conn: list,
global_load: np.ndarray,
fixed_nodes: list,
nx: int,
ny: int
) -> None:
"""
保存图1:原始网格与完整标注(单元/节点/荷载/约束)"""
fig, ax = plt.subplots(figsize=(14, 8)) # 增大画布尺寸
ax.set_title('原始网格与完整标注(单元/节点/荷载/约束)', fontsize=14, fontweight='bold', pad=15)
ax.set_xlabel('x (m)', fontsize=12)
ax.set_ylabel('y (m)', fontsize=12)

# 1. 绘制网格线
for i in range(nx):
ax.plot(node_x[i, :], node_y[i, :], 'k-', linewidth=0.8, alpha=0.7)
for j in range(ny):
ax.plot(node_x[:, j], node_y[:, j], 'k-', linewidth=0.8, alpha=0.7)

# 2. 标注节点编码(全局编号)
node_flat_x = node_x.flatten()
node_flat_y = node_y.flatten()
for node_idx in range(nx*ny):
ax.text(
node_flat_x[node_idx] + 0.05, node_flat_y[node_idx] + 0.05,
f"{node_idx+1}", fontsize=8, color='darkblue', fontweight='bold'
)

# 3. 标注单元划分与单元编号
for elem_id, elem_nodes in enumerate(elem_conn):
elem_node_idx = [n-1 for n in elem_nodes]
elem_center_x = np.mean(node_flat_x[elem_node_idx])
elem_center_y = np.mean(node_flat_y[elem_node_idx])
ax.text(
elem_center_x, elem_center_y, f"E{elem_id+1}",
fontsize=9, color='darkgreen', fontweight='bold',
bbox=dict(boxstyle="round,pad=0.2", facecolor='white', alpha=0.7)
)

# 4. 标注等效节点荷载(上表面节点,x方向荷载)
arrow_length_scale = 1e-5 # 荷载箭头长度缩放因子
for i, node_idx in enumerate(top_nodes):
load_x = global_load[2*node_idx, 0]
if abs(load_x) > TINY_VALUE:
ax.arrow(
node_flat_x[node_idx], node_flat_y[node_idx],
load_x * arrow_length_scale, 0,
head_width=0.03, head_length=0.08, fc='red', ec='red', alpha=0.8, zorder=5
)
ax.text(
node_flat_x[node_idx] + 0.1, node_flat_y[node_idx] + 0.03,
f"F={load_x:.1f}N", fontsize=7, color='red', fontweight='bold'
)

# 5. 标注位移约束(修改:仅保留红色十字叉,删除文字和背景框)
for node_idx in fixed_nodes:
ax.plot(
node_flat_x[node_idx], node_flat_y[node_idx],
'rx', markersize=8, markeredgewidth=2, zorder=6
)

# 6. 图例与样式设置
ax.scatter([], [], c='darkblue', label='节点编码', s=20)
ax.scatter([], [], c='darkgreen', label='单元编码', s=20)
ax.arrow(0, 0, 0, 0, fc='red', ec='red', label='等效节点荷载', head_width=0.03)
ax.plot([], [], 'rx', markersize=8, markeredgewidth=2, label='位移约束')
# 调整图例位置到右上角外侧,避免重叠
ax.legend(loc='upper left', bbox_to_anchor=(1.02, 1), fontsize=10, framealpha=0.9)

ax.set_aspect('equal')
ax.grid(True, alpha=0.3, linestyle='--')
# 修改:大幅增大显示范围(x轴-1.0~6.0,y轴-1.0~1.0),彻底避免图例重叠
ax.set_xlim(-1.0, BEAM_LENGTH + 1.0)
ax.set_ylim(-1.0, 1.0)

filename = f'悬臂梁_原始网格_完整标注_{nx}x{ny}.png'
plt.savefig(filename, dpi=300, bbox_inches='tight')
print(f"已保存: {filename}")
plt.close()

def save_disp_x_plot(node_x: np.ndarray, node_y: np.ndarray, disp_x: np.ndarray, nx: int, ny: int) -> None:
"""保存图2:水平位移云图"""
fig, ax = plt.subplots(figsize=(10, 6))
disp_contour = disp_x.reshape(nx, ny)
contour = ax.contourf(node_x, node_y, disp_contour, levels=50, cmap='coolwarm')

ax.set_title('水平位移 u_x 云图', fontsize=14, fontweight='bold')
ax.set_xlabel('x (m)')
ax.set_ylabel('y (m)')
cbar = plt.colorbar(contour, ax=ax, format='%.2e', shrink=0.8)
cbar.set_label('位移值 (m)', rotation=270, labelpad=20)

ax.set_aspect('equal')
ax.grid(True, alpha=0.3, linestyle='--')

filename = f'悬臂梁_水平位移_{nx}x{ny}.png'
plt.savefig(filename, bbox_inches='tight')
print(f"已保存: {filename}")
plt.close()

def save_stress_x_plot(node_x: np.ndarray, node_y: np.ndarray, stress_x: np.ndarray, nx: int, ny: int) -> None:
"""保存图3:轴向应力云图"""
fig, ax = plt.subplots(figsize=(10, 6))
stress_contour = stress_x.reshape(nx, ny)
contour = ax.contourf(node_x, node_y, stress_contour, levels=50, cmap='RdBu_r')

ax.set_title('轴向应力 σ_x 云图 (MPa)', fontsize=14, fontweight='bold')
ax.set_xlabel('x (m)')
ax.set_ylabel('y (m)')
cbar = plt.colorbar(contour, ax=ax, format='%.1f', shrink=0.8)
cbar.set_label('应力值 (MPa)', rotation=270, labelpad=20)

ax.set_aspect('equal')
ax.grid(True, alpha=0.3, linestyle='--')

filename = f'悬臂梁_轴向应力_{nx}x{ny}.png'
plt.savefig(filename, bbox_inches='tight')
print(f"已保存: {filename}")
plt.close()

def save_deformed_mesh_plot(
node_x: np.ndarray,
node_y: np.ndarray,
def_x: np.ndarray,
def_y: np.ndarray,
nx: int,
ny: int
) -> None:
"""保存图4:变形后网格 """
fig, ax = plt.subplots(figsize=(10, 6))
ax.set_title(f'变形后网格(位移放大{DISP_SCALE_FACTOR}倍)', fontsize=14, fontweight='bold')
ax.set_xlabel('x (m)')
ax.set_ylabel('y (m)')

# 修改:未变形网格改为黑色实线,线宽0.8(略细于变形网格)
for i in range(nx):
ax.plot(node_x[i, :], node_y[i, :], 'k-', linewidth=0.8, alpha=0.6)
for j in range(ny):
ax.plot(node_x[:, j], node_y[:, j], 'k-', linewidth=0.8, alpha=0.6)

# 变形网格(红色实线,线宽1.5)
def_x_scaled = node_x + (def_x - node_x) * DISP_SCALE_FACTOR
def_y_scaled = node_y + (def_y - node_y) * DISP_SCALE_FACTOR
for i in range(nx):
ax.plot(def_x_scaled[i, :], def_y_scaled[i, :], 'r-', linewidth=1.5, alpha=0.8)
for j in range(ny):
ax.plot(def_x_scaled[:, j], def_y_scaled[:, j], 'r-', linewidth=1.5, alpha=0.8)

ax.set_aspect('equal')
ax.grid(True, alpha=0.3, linestyle='--')
ax.set_xlim(-1.0, BEAM_LENGTH + 1.0)
ax.set_ylim(-1.0, 1.0)

filename = f'悬臂梁_变形网格_{nx}x{ny}.png'
plt.savefig(filename, bbox_inches='tight')
print(f"已保存: {filename}")
plt.close()

def save_disp_y_plot(node_x: np.ndarray, node_y: np.ndarray, disp_y: np.ndarray, nx: int, ny: int) -> None:
"""保存图5:竖向位移云图"""
fig, ax = plt.subplots(figsize=(10, 6))
disp_contour = disp_y.reshape(nx, ny)
contour = ax.contourf(node_x, node_y, disp_contour, levels=50, cmap='coolwarm')

ax.set_title('竖向位移 u_y 云图', fontsize=14, fontweight='bold')
ax.set_xlabel('x (m)')
ax.set_ylabel('y (m)')
cbar = plt.colorbar(contour, ax=ax, format='%.2e', shrink=0.8)
cbar.set_label('位移值 (m)', rotation=270, labelpad=20)

ax.set_aspect('equal')
ax.grid(True, alpha=0.3, linestyle='--')

filename = f'悬臂梁_竖向位移_{nx}x{ny}.png'
plt.savefig(filename, bbox_inches='tight')
print(f"已保存: {filename}")
plt.close()

def save_stress_xy_plot(node_x: np.ndarray, node_y: np.ndarray, stress_xy: np.ndarray, nx: int, ny: int) -> None:
"""保存图6:剪切应力云图"""
fig, ax = plt.subplots(figsize=(10, 6))
stress_contour = stress_xy.reshape(nx, ny)
contour = ax.contourf(node_x, node_y, stress_contour, levels=50, cmap='viridis')

ax.set_title('剪切应力 τ_xy 云图 (MPa)', fontsize=14, fontweight='bold')
ax.set_xlabel('x (m)')
ax.set_ylabel('y (m)')
cbar = plt.colorbar(contour, ax=ax, format='%.1f', shrink=0.8)
cbar.set_label('应力值 (MPa)', rotation=270, labelpad=20)

ax.set_aspect('equal')
ax.grid(True, alpha=0.3, linestyle='--')

filename = f'悬臂梁_剪切应力_{nx}x{ny}.png'
plt.savefig(filename, bbox_inches='tight')
print(f"已保存: {filename}")
plt.close()


# ===================== 6. 主分析流程 =====================
def run_fea_analysis() -> Dict[str, Any]:
"""悬臂梁平面应力有限元分析主函数"""
print("="*60)
print("等截面悬臂梁平面应力有限元分析程序 v2.4")
print("="*60)

try:
# 1. 网格参数输入
print("\n[1/6] 输入网格参数")
print("-"*40)
nx = get_valid_integer_input("水平方向节点数(≥2): ")
ny = get_valid_integer_input("竖直方向节点数(≥2): ")

ne_x = nx - 1
ne_y = ny - 1
n_nodes = nx * ny
n_elems = ne_x * ne_y

print(f"\n网格信息:")
print(f" 节点数: {n_nodes} ({nx}×{ny}) | 单元数: {n_elems} ({ne_x}×{ne_y})")
print(f" 提示:增加节点数可降低计算误差")

# 2. 打印参数配置
print("\n[2/6] 材料与几何参数")
print("-"*40)
print(f"几何参数:长度={BEAM_LENGTH}m | 高度={BEAM_HEIGHT}m | 厚度={BEAM_THICKNESS}m")
print(f"材料参数:E={ELASTIC_MODULUS:.4e}Pa | ν={POISSON_RATIO} | 剪应力={APPLIED_SHEAR_STRESS:.4e}Pa")

# 3. 理论解展示
print("\n[3/6] 理论解")
print("-"*40)
theory = {
"自由端水平位移(m)": THEORY_DISP_X,
"自由端竖向位移(m)": THEORY_DISP_Y
}
for k, v in theory.items():
print(f" {k}: {v:.8e}")

# 4. 生成网格
print("\n[4/6] 生成有限元网格")
print("-"*40)
node_x = np.zeros((nx, ny), dtype=FLOAT_TYPE)
node_y = np.zeros((nx, ny), dtype=FLOAT_TYPE)

x_coords = np.linspace(0, BEAM_LENGTH, nx, dtype=FLOAT_TYPE)
y_coords = np.linspace(-BEAM_HEIGHT/2, BEAM_HEIGHT/2, ny, dtype=FLOAT_TYPE)

for i in range(nx):
node_x[i, :] = x_coords[i]
for j in range(ny):
node_y[:, j] = y_coords[j]

print(f"坐标范围:x=[{node_x.min():.6f}, {node_x.max():.6f}]m | y=[{node_y.min():.6f}, {node_y.max():.6f}]m")

# 5. 生成单元连接表
elem_conn = []
for i in range(ne_x):
for j in range(ne_y):
n1 = i * ny + j + 1
n2 = (i+1) * ny + j + 1
n3 = (i+1) * ny + j + 2
n4 = i * ny + j + 2
elem_conn.append([n1, n2, n3, n4])

# 6. 本构矩阵计算
D = (ELASTIC_MODULUS / (1 - POISSON_RATIO**2)) * np.array([
[1, POISSON_RATIO, 0],
[POISSON_RATIO, 1, 0],
[0, 0, (1-POISSON_RATIO)/2]
], dtype=FLOAT_TYPE)

# 7. 高斯积分点初始化
gauss_pts, gauss_wts = leggauss(GAUSS_ORDER)

# 8. 组装全局刚度矩阵和荷载向量
print("\n[5/6] 组装刚度矩阵与荷载向量")
print("-"*40)
K = np.zeros((2*n_nodes, 2*n_nodes), dtype=FLOAT_TYPE)
F = np.zeros((2*n_nodes, 1), dtype=FLOAT_TYPE)

for elem_id, elem_nodes in enumerate(elem_conn):
if (elem_id+1) % max(1, n_elems//10) == 0:
progress = (elem_id+1)/n_elems*100
print(f" 处理单元 {elem_id+1}/{n_elems} ({progress:.0f}%)")

elem_idx = [n-1 for n in elem_nodes]
elem_x = node_x.flatten()[elem_idx]
elem_y = node_y.flatten()[elem_idx]

is_top_elem = np.max(elem_y) >= (BEAM_HEIGHT/2 - TINY_VALUE)
ke = np.zeros((8, 8), dtype=FLOAT_TYPE)

for i in range(GAUSS_ORDER):
for j in range(GAUSS_ORDER):
s = gauss_pts[i]
t = gauss_pts[j]

dN_ds, dN_dt = quad4_shape_derivatives(s, t)
jac, det_jac, inv_jac = calculate_jacobian(dN_ds, dN_dt, elem_x, elem_y)

dN_dx = inv_jac[0,0]*dN_ds + inv_jac[0,1]*dN_dt
dN_dy = inv_jac[1,0]*dN_ds + inv_jac[1,1]*dN_dt

B = calculate_B_matrix(dN_dx, dN_dy)
weight = gauss_wts[i] * gauss_wts[j] * det_jac * BEAM_THICKNESS
ke += B.T @ D @ B * weight

if is_top_elem:
fe = calculate_surface_load(elem_x, elem_y, APPLIED_SHEAR_STRESS, BEAM_THICKNESS)
for local_i, global_i in enumerate(elem_idx):
F[2*global_i, 0] += fe[2*local_i]
F[2*global_i+1, 0] += fe[2*local_i+1]

for local_i, global_i in enumerate(elem_idx):
for local_j, global_j in enumerate(elem_idx):
K[2*global_i:2*global_i+2, 2*global_j:2*global_j+2] += ke[2*local_i:2*local_i+2, 2*local_j:2*local_j+2]

# 9. 荷载信息
total_load = np.sum(F)
theory_load = APPLIED_SHEAR_STRESS * BEAM_THICKNESS * BEAM_LENGTH
print(f"\n荷载信息:")
print(f" 总施加荷载: {total_load:.6f}N | 理论总荷载: {theory_load:.6f}N")
print(f" 荷载误差: {abs(total_load - theory_load):.6e}N")

# 10. 边界条件处理(左端固定)
print("\n[6/6] 求解位移与应力")
print("-"*40)
fixed_nodes = list(range(ny)) # 左端节点索引
fixed_dofs = []
for n in fixed_nodes:
fixed_dofs.append(2*n)
fixed_dofs.append(2*n+1)

free_dofs = [d for d in range(2*n_nodes) if d not in fixed_dofs]
K_red = K[np.ix_(free_dofs, free_dofs)]
F_red = F[free_dofs, :]

cond_num = np.linalg.cond(K_red)
print(f"刚度矩阵条件数: {cond_num:.2e}")
if cond_num > 1e10:
print("警告:条件数较大,建议加密网格")

# 求解位移
u_red = np.linalg.solve(K_red, F_red)
u = np.zeros((2*n_nodes, 1), dtype=FLOAT_TYPE)
u[free_dofs, :] = u_red

disp_x = u[::2].flatten()
disp_y = u[1::2].flatten()

print(f"\n位移范围:")
print(f" 水平位移: [{disp_x.min():.8e}, {disp_x.max():.8e}]m")
print(f" 竖向位移: [{disp_y.min():.8e}, {disp_y.max():.8e}]m")

# 11. 提取自由端中点位移
print("\n后处理:提取自由端中点位移")
print("-"*40)
fem_dx, fem_dy = get_free_end_mid_disp(u, node_x, node_y)
fem = {
"自由端水平位移(m)": fem_dx,
"自由端竖向位移(m)": fem_dy
}
print(f" 水平位移: {fem_dx:.8e}m | 竖向位移: {fem_dy:.8e}m")

# 12. 单元应力计算
print("\n后处理:计算单元应力")
print("-"*40)
elem_stress = np.zeros((n_elems, 3), dtype=FLOAT_TYPE)

for elem_id, elem_nodes in enumerate(elem_conn):
elem_idx = [n-1 for n in elem_nodes]

ue = np.zeros(8, dtype=FLOAT_TYPE)
for local_i, global_i in enumerate(elem_idx):
ue[2*local_i] = u[2*global_i, 0]
ue[2*local_i+1] = u[2*global_i+1, 0]

elem_x = node_x.flatten()[elem_idx]
elem_y = node_y.flatten()[elem_idx]

stress_avg = np.zeros(3, dtype=FLOAT_TYPE)
count = 0

for i in range(GAUSS_ORDER):
for j in range(GAUSS_ORDER):
count += 1
s = gauss_pts[i]
t = gauss_pts[j]

dN_ds, dN_dt = quad4_shape_derivatives(s, t)
jac, det_jac, inv_jac = calculate_jacobian(dN_ds, dN_dt, elem_x, elem_y)

dN_dx = inv_jac[0,0]*dN_ds + inv_jac[0,1]*dN_dt
dN_dy = inv_jac[1,0]*dN_ds + inv_jac[1,1]*dN_dt

B = calculate_B_matrix(dN_dx, dN_dy)
strain = B @ ue
stress = D @ strain

stress_avg += stress

elem_stress[elem_id, :] = stress_avg / count

print(f"应力范围:")
print(f" 轴向应力: [{elem_stress[:,0].min():.4e}, {elem_stress[:,0].max():.4e}]Pa")
print(f" 剪切应力: [{elem_stress[:,2].min():.4e}, {elem_stress[:,2].max():.4e}]Pa")

# 13. 结果对比
print_result_compare(theory, fem)

# 14. 误差分析
dx_err = abs((fem_dx - THEORY_DISP_X)/THEORY_DISP_X)*100
dy_err = abs((fem_dy - THEORY_DISP_Y)/THEORY_DISP_Y)*100
print(f"\n误差分析:")
print(f" 水平位移相对误差: {dx_err:.4f}%")
print(f" 竖向位移相对误差: {dy_err:.4f}%")
if dx_err < 1.0:
print(f" ✅ 水平位移误差<1%,满足工程精度要求")

# 15. 可视化准备
print("\n生成可视化结果")
print("-"*40)

def_x = node_x.flatten() + disp_x
def_y = node_y.flatten() + disp_y
def_x = def_x.reshape(nx, ny)
def_y = def_y.reshape(nx, ny)

# 节点应力平均
node_stress_x = np.zeros(n_nodes, dtype=FLOAT_TYPE)
node_stress_xy = np.zeros(n_nodes, dtype=FLOAT_TYPE)
node_count_x = np.zeros(n_nodes, dtype=int)
node_count_xy = np.zeros(n_nodes, dtype=int)

for elem_id, elem_nodes in enumerate(elem_conn):
sx = elem_stress[elem_id, 0]
sxy = elem_stress[elem_id, 2]
for n in elem_nodes:
idx = n-1
node_stress_x[idx] += sx
node_stress_xy[idx] += sxy
node_count_x[idx] += 1
node_count_xy[idx] += 1

node_stress_x_avg = node_stress_x / node_count_x / 1e6
node_stress_xy_avg = node_stress_xy / node_count_xy / 1e6

top_nodes = [i*ny + (ny-1) for i in range(nx)] # 上表面节点索引

# 调用可视化函数(删除了冗余的网格划分与单元图)
print("\n保存图片文件:")
print("-"*40)
save_mesh_plot_with_annotations(node_x, node_y, top_nodes, elem_conn, F, fixed_nodes, nx, ny)
save_disp_x_plot(node_x, node_y, disp_x, nx, ny)
save_stress_x_plot(node_x, node_y, node_stress_x_avg, nx, ny)
save_deformed_mesh_plot(node_x, node_y, def_x, def_y, nx, ny)
save_disp_y_plot(node_x, node_y, disp_y, nx, ny)
save_stress_xy_plot(node_x, node_y, node_stress_xy_avg, nx, ny)

# 返回分析结果
return {
'nodal_displacements': u,
'element_stresses': elem_stress,
'mesh_info': {'nx': nx, 'ny': ny, 'n_nodes': n_nodes, 'n_elems': n_elems},
'theory_solution': theory,
'fem_solution': fem,
'error': {'dx_err': dx_err, 'dy_err': dy_err}
}

except Exception as e:
print(f"\n程序执行错误: {str(e)}")
traceback.print_exc()
return None


# ===================== 7. 程序入口 =====================
if __name__ == "__main__":
results = run_fea_analysis()
if results:
print("\n✅ 悬臂梁有限元分析完成!")
if results['error']['dx_err'] < 1.0:
print(f"📊 水平位移相对误差 {results['error']['dx_err']:.4f}%,达到高精度要求")
else:
print("\n❌ 程序执行失败,请检查错误信息")

2.2 三结点三边形单元有限元Python程序

  源代码已上传github,详见链接。

1
2
3
4
5
6
7
8
9
10
11
12
13
14
15
16
17
18
19
20
21
22
23
24
25
26
27
28
29
30
31
32
33
34
35
36
37
38
39
40
41
42
43
44
45
46
47
48
49
50
51
52
53
54
55
56
57
58
59
60
61
62
63
64
65
66
67
68
69
70
71
72
73
74
75
76
77
78
79
80
81
82
83
84
85
86
87
88
89
90
91
92
93
94
95
96
97
98
99
100
101
102
103
104
105
106
107
108
109
110
111
112
113
114
115
116
117
118
119
120
121
122
123
124
125
126
127
128
129
130
131
132
133
134
135
136
137
138
139
140
141
142
143
144
145
146
147
148
149
150
151
152
153
154
155
156
157
158
159
160
161
162
163
164
165
166
167
168
169
170
171
172
173
174
175
176
177
178
179
180
181
182
183
184
185
186
187
188
189
190
191
192
193
194
195
196
197
198
199
200
201
202
203
204
205
206
207
208
209
210
211
212
213
214
215
216
217
218
219
220
221
222
223
224
225
226
227
228
229
230
231
232
233
234
235
236
237
238
239
240
241
242
243
244
245
246
247
248
249
250
251
252
253
254
255
256
257
258
259
260
261
262
263
264
265
266
267
268
269
270
271
272
273
274
275
276
277
278
279
280
281
282
283
284
285
286
287
288
289
290
291
292
293
294
295
296
297
298
299
300
301
302
303
304
305
306
307
308
309
310
311
312
313
314
315
316
317
318
319
320
321
322
323
324
325
326
327
328
329
330
331
332
333
334
335
336
337
338
339
340
341
342
343
344
345
346
347
348
349
350
351
352
353
354
355
356
357
358
359
360
361
362
363
364
365
366
367
368
369
370
371
372
373
374
375
376
377
378
379
380
381
382
383
384
385
386
387
388
389
390
391
392
393
394
395
396
397
398
399
400
401
402
403
404
405
406
407
408
409
410
411
412
413
414
415
416
417
418
419
420
421
422
423
424
425
426
427
428
429
430
431
432
433
434
435
436
437
438
439
440
441
442
443
444
445
446
447
448
449
450
451
452
453
454
455
456
457
458
459
460
461
462
463
464
465
466
467
468
469
470
471
472
473
474
475
476
477
478
479
480
481
482
483
484
485
486
487
488
489
490
491
492
493
494
495
496
497
498
499
500
501
502
503
504
505
506
507
508
509
510
511
512
513
514
515
516
517
518
519
520
521
522
523
524
525
526
527
528
529
530
531
532
533
534
535
536
537
538
539
540
541
542
543
544
545
546
547
548
549
550
551
552
553
554
555
556
557
558
559
560
561
562
563
564
565
566
567
568
569
570
571
572
573
574
575
576
577
578
579
580
581
582
583
584
585
586
587
588
589
590
591
592
593
594
595
596
597
598
599
600
601
602
603
604
605
606
607
608
609
610
611
612
613
614
615
616
617
618
619
620
621
622
623
624
625
626
627
628
629
630
631
632
633
634
635
636
637
638
639
640
641
642
643
644
645
646
647
648
649
650
651
652
653
654
655
656
657
658
659
660
661
662
663
664
665
666
667
668
669
670
671
672
673
674
675
676
677
678
"""
等截面悬臂梁平面应力有限元分析程序(三结点三角形单元版 v2.4.2)

核心功能:
1. 基于四节点三角形单元实现悬臂梁平面应力有限元全流程分析
2. 保留原程序的高精度位移提取、可视化、结果对比功能
3. 生成6张高清可视化图片
"""


# ===================== 1. 导入依赖库 =====================
import traceback
from typing import Tuple, Dict, Any

import numpy as np
import matplotlib.pyplot as plt
import matplotlib
from numpy.polynomial.legendre import leggauss
from scipy.interpolate import interp1d


# ===================== 2. 全局配置 =====================
# 绘图配置
matplotlib.rcParams['font.sans-serif'] = ['Microsoft YaHei', 'SimHei', 'PingFang SC']
matplotlib.rcParams['axes.unicode_minus'] = False
matplotlib.rcParams['figure.dpi'] = 120
matplotlib.rcParams['savefig.dpi'] = 300

# 几何参数(与理论解严格匹配)
BEAM_LENGTH = 5.0 # 梁总长 (m)
BEAM_HEIGHT = 1.0 # 梁截面高度 (m)
BEAM_THICKNESS = 0.1 # 梁厚度(平面应力)(m)

# 材料参数
ELASTIC_MODULUS = 190e9 # 弹性模量 (Pa)
POISSON_RATIO = 0.25 # 泊松比
APPLIED_SHEAR_STRESS = 10e6 # 顶部剪应力 (Pa)

# 理论解(基于上述参数推导)
THEORY_DISP_X = 0.00131578947368 # 自由端水平位移 (m)
THEORY_DISP_Y = -0.0130921052632 # 自由端竖向位移 (m)

# 数值计算参数(三角形单元适配)
TRI_INTEG_ORDER = 1 # 三角形1点积分(常应变单元最优)
TINY_VALUE = 1e-15 # 数值稳定性极小值
FLOAT_TYPE = np.float64 # 双精度浮点类型
DISP_SCALE_FACTOR = 10 # 位移放大因子

# 三角形单元高斯积分点(面积坐标)和权重
TRI_INTEG_POINTS = np.array([[1/3, 1/3, 1/3]], dtype=FLOAT_TYPE) # 1点积分(单元中心)
TRI_INTEG_WEIGHTS = np.array([1/2], dtype=FLOAT_TYPE) # 积分权重


# ===================== 3. 输入处理工具函数 =====================
def get_valid_integer_input(prompt: str, min_value: int = 2) -> int:
"""
获取用户输入的有效正整数,包含输入合法性验证

Args:
prompt: 输入提示文本
min_value: 输入最小值(默认2,保证至少1个单元)

Returns:
验证通过的正整数
"""
while True:
try:
user_input = int(input(prompt))
if user_input >= min_value:
return user_input
print(f"错误:数值必须≥{min_value},请重新输入")
except ValueError:
print("错误:请输入有效正整数(如5、10、20)")


# ===================== 4. 三角形单元核心计算函数 =====================
def tri3_shape_functions(l1: float, l2: float, l3: float) -> np.ndarray:
"""计算3节点三角形单元形函数值(面积坐标L1,L2,L3)"""
# 三角形线性形函数:N1=L1, N2=L2, N3=L3
return np.array([l1, l2, l3], dtype=FLOAT_TYPE)

def tri3_shape_derivatives(elem_x: np.ndarray, elem_y: np.ndarray) -> Tuple[np.ndarray, np.ndarray]:
"""
计算3节点三角形单元形函数对物理坐标的偏导数
公式:dN/dx = (1/2A) * [ (y2-y3), (y3-y1), (y1-y2) ]
dN/dy = (1/2A) * [ (x3-x2), (x1-x3), (x2-x1) ]
"""
# 单元节点坐标
x1, x2, x3 = elem_x
y1, y2, y3 = elem_y

# 单元面积×2
two_A = (x2 - x1)*(y3 - y1) - (x3 - x1)*(y2 - y1)
if abs(two_A) < TINY_VALUE:
raise ValueError(f"三角形单元面积过小({two_A:.2e}),数值不稳定")

# 形函数对x/y的偏导数
dN_dx = np.array([
(y2 - y3)/two_A,
(y3 - y1)/two_A,
(y1 - y2)/two_A
], dtype=FLOAT_TYPE)

dN_dy = np.array([
(x3 - x2)/two_A,
(x1 - x3)/two_A,
(x2 - x1)/two_A
], dtype=FLOAT_TYPE)

return dN_dx, dN_dy

def calculate_tri_B_matrix(dN_dx: np.ndarray, dN_dy: np.ndarray) -> np.ndarray:
"""计算三角形单元应变-位移矩阵B(ε = B·u,3×6维度)"""
B = np.zeros((3, 6), dtype=FLOAT_TYPE)
for i in range(3):
u_idx = 2 * i
v_idx = 2 * i + 1
B[0, u_idx] = dN_dx[i] # ε_xx = ∂u/∂x
B[1, v_idx] = dN_dy[i] # ε_yy = ∂v/∂y
B[2, u_idx] = dN_dy[i] # γ_xy = ∂u/∂y + ∂v/∂x
B[2, v_idx] = dN_dx[i]
return B

def calculate_tri_surface_load(
elem_x: np.ndarray,
elem_y: np.ndarray,
stress: float,
thickness: float,
is_top_edge: bool
) -> np.ndarray:
"""计算三角形单元面荷载的等效节点荷载(顶部边荷载)"""
elem_load = np.zeros(6, dtype=FLOAT_TYPE)

# 确定顶部边的两个节点(y坐标最大的两个节点)
if is_top_edge:
y_vals = elem_y
top_node_idx = np.argsort(y_vals)[-2:] # 取y最大的两个节点
x1, x2 = elem_x[top_node_idx]
y1, y2 = elem_y[top_node_idx]

# 边长度
edge_len = np.sqrt((x2-x1)**2 + (y2-y1)**2)
# 均布荷载等效到两个节点(各承担一半)
load_mag = stress * thickness * edge_len / 2.0

for idx in top_node_idx:
elem_load[2*idx] = load_mag # x方向荷载

return elem_load

def get_free_end_mid_disp(
disp: np.ndarray,
node_x: np.ndarray,
node_y: np.ndarray
) -> Tuple[float, float]:
"""精准提取自由端(x=梁长)几何中点的位移(适配奇偶节点数)"""
nx, ny = node_x.shape
free_end_idx = []
free_end_y = []
free_end_dx = []
free_end_dy = []

for j in range(ny):
global_idx = (nx-1)*ny + j
if abs(node_x[nx-1, j] - BEAM_LENGTH) < TINY_VALUE:
free_end_idx.append(global_idx)
free_end_y.append(node_y[nx-1, j])
free_end_dx.append(disp[2*global_idx, 0])
free_end_dy.append(disp[2*global_idx+1, 0])

free_end_y = np.array(free_end_y, dtype=FLOAT_TYPE)
mid_y = (free_end_y.min() + free_end_y.max()) / 2.0

interp_dx = interp1d(free_end_y, free_end_dx, kind='linear', fill_value="extrapolate")
interp_dy = interp1d(free_end_y, free_end_dy, kind='linear', fill_value="extrapolate")

return float(interp_dx(mid_y)), float(interp_dy(mid_y))

def print_result_compare(theory: Dict[str, float], fem: Dict[str, float]) -> None:
"""格式化打印有限元解与理论解的对比表格"""
print("\n" + "="*85)
print("有限元解与理论解对比表(三结点三角形单元)")
print("="*85)
print(f"{'分析项目':<25} {'理论解':<20} {'有限元解':<20} {'相对误差(%)':<15}")
print("-"*85)

for item in theory.keys():
t_val = theory[item]
f_val = fem[item]
err = abs((f_val - t_val)/t_val)*100 if abs(t_val) > TINY_VALUE else 100.0
print(f"{item:<25} {t_val:<20.8e} {f_val:<20.8e} {err:<15.4f}")

print("="*85)


# ===================== 5. 可视化函数 =====================
def save_mesh_plot_with_annotations(
node_x: np.ndarray,
node_y: np.ndarray,
top_nodes: list,
elem_conn: list,
global_load: np.ndarray,
fixed_nodes: list,
nx: int,
ny: int
) -> None:
"""保存图1:原始网格与完整标注(三角形单元适配)"""
fig, ax = plt.subplots(figsize=(14, 8))
ax.set_title('原始网格与完整标注(三结点三角形单元)', fontsize=14, fontweight='bold', pad=15)
ax.set_xlabel('x (m)', fontsize=12)
ax.set_ylabel('y (m)', fontsize=12)

# 1. 绘制三角形单元网格
for elem_nodes in elem_conn:
elem_idx = [n-1 for n in elem_nodes]
elem_x = node_x.flatten()[elem_idx]
elem_y = node_y.flatten()[elem_idx]
# 闭合三角形绘制
elem_x_plot = np.append(elem_x, elem_x[0])
elem_y_plot = np.append(elem_y, elem_y[0])
ax.plot(elem_x_plot, elem_y_plot, 'k-', linewidth=0.8, alpha=0.7)

# 2. 标注节点编码(全局编号)
node_flat_x = node_x.flatten()
node_flat_y = node_y.flatten()
for node_idx in range(nx*ny):
ax.text(
node_flat_x[node_idx] + 0.05, node_flat_y[node_idx] + 0.05,
f"{node_idx+1}", fontsize=8, color='darkblue', fontweight='bold'
)

# 3. 标注单元编号
for elem_id, elem_nodes in enumerate(elem_conn):
elem_idx = [n-1 for n in elem_nodes]
elem_center_x = np.mean(node_x.flatten()[elem_idx])
elem_center_y = np.mean(node_y.flatten()[elem_idx])
ax.text(
elem_center_x, elem_center_y, f"E{elem_id+1}",
fontsize=8, color='darkgreen', fontweight='bold',
bbox=dict(boxstyle="round,pad=0.2", facecolor='white', alpha=0.7)
)

# 4. 标注等效节点荷载
arrow_length_scale = 1e-5
for i, node_idx in enumerate(top_nodes):
load_x = global_load[2*node_idx, 0]
if abs(load_x) > TINY_VALUE:
ax.arrow(
node_flat_x[node_idx], node_flat_y[node_idx],
load_x * arrow_length_scale, 0,
head_width=0.03, head_length=0.08, fc='red', ec='red', alpha=0.8, zorder=5
)
ax.text(
node_flat_x[node_idx] + 0.1, node_flat_y[node_idx] + 0.03,
f"F={load_x:.1f}N", fontsize=7, color='red', fontweight='bold'
)

# 5. 标注位移约束(仅红色十字叉)
for node_idx in fixed_nodes:
ax.plot(
node_flat_x[node_idx], node_flat_y[node_idx],
'rx', markersize=8, markeredgewidth=2, zorder=6
)

# 6. 图例与样式设置
ax.scatter([], [], c='darkblue', label='节点编码', s=20)
ax.scatter([], [], c='darkgreen', label='单元编码', s=20)
ax.arrow(0, 0, 0, 0, fc='red', ec='red', label='等效节点荷载', head_width=0.03)
ax.plot([], [], 'rx', markersize=8, markeredgewidth=2, label='位移约束')
ax.legend(loc='upper left', bbox_to_anchor=(1.02, 1), fontsize=10, framealpha=0.9)

ax.set_aspect('equal')
ax.grid(True, alpha=0.3, linestyle='--')
ax.set_xlim(-1.0, BEAM_LENGTH + 1.0)
ax.set_ylim(-1.0, 1.0)

filename = f'悬臂梁_原始网格_三角形单元_{nx}x{ny}.png'
plt.savefig(filename, dpi=300, bbox_inches='tight')
print(f"已保存: {filename}")
plt.close()

def save_disp_x_plot(node_x: np.ndarray, node_y: np.ndarray, disp_x: np.ndarray, nx: int, ny: int) -> None:
"""保存图2:水平位移云图"""
fig, ax = plt.subplots(figsize=(10, 6))
disp_contour = disp_x.reshape(nx, ny)
contour = ax.contourf(node_x, node_y, disp_contour, levels=50, cmap='coolwarm')

ax.set_title('水平位移 u_x 云图(三角形单元)', fontsize=14, fontweight='bold')
ax.set_xlabel('x (m)')
ax.set_ylabel('y (m)')
cbar = plt.colorbar(contour, ax=ax, format='%.2e', shrink=0.8)
cbar.set_label('位移值 (m)', rotation=270, labelpad=20)

ax.set_aspect('equal')
ax.grid(True, alpha=0.3, linestyle='--')

filename = f'悬臂梁_水平位移_三角形单元_{nx}x{ny}.png'
plt.savefig(filename, bbox_inches='tight')
print(f"已保存: {filename}")
plt.close()

def save_stress_x_plot(node_x: np.ndarray, node_y: np.ndarray, stress_x: np.ndarray, nx: int, ny: int) -> None:
"""保存图3:轴向应力云图"""
fig, ax = plt.subplots(figsize=(10, 6))
stress_contour = stress_x.reshape(nx, ny)
contour = ax.contourf(node_x, node_y, stress_contour, levels=50, cmap='RdBu_r')

ax.set_title('轴向应力 σ_x 云图 (MPa)(三角形单元)', fontsize=14, fontweight='bold')
ax.set_xlabel('x (m)')
ax.set_ylabel('y (m)')
cbar = plt.colorbar(contour, ax=ax, format='%.1f', shrink=0.8)
cbar.set_label('应力值 (MPa)', rotation=270, labelpad=20)

ax.set_aspect('equal')
ax.grid(True, alpha=0.3, linestyle='--')

filename = f'悬臂梁_轴向应力_三角形单元_{nx}x{ny}.png'
plt.savefig(filename, bbox_inches='tight')
print(f"已保存: {filename}")
plt.close()

def save_deformed_mesh_plot(
node_x: np.ndarray,
node_y: np.ndarray,
def_x: np.ndarray,
def_y: np.ndarray,
elem_conn: list, # 修复:添加elem_conn参数
nx: int,
ny: int
) -> None:
"""保存图4:变形后网格(三角形单元适配)"""
fig, ax = plt.subplots(figsize=(10, 6))
ax.set_title(f'变形后网格(位移放大{DISP_SCALE_FACTOR}倍,三角形单元)', fontsize=14, fontweight='bold')
ax.set_xlabel('x (m)')
ax.set_ylabel('y (m)')

# 未变形网格(黑色实线)
node_flat_x = node_x.flatten()
node_flat_y = node_y.flatten()
for elem_nodes in elem_conn:
elem_idx = [n-1 for n in elem_nodes]
elem_x = node_flat_x[elem_idx]
elem_y = node_flat_y[elem_idx]
elem_x_plot = np.append(elem_x, elem_x[0])
elem_y_plot = np.append(elem_y, elem_y[0])
ax.plot(elem_x_plot, elem_y_plot, 'k-', linewidth=0.8, alpha=0.6)

# 变形网格(红色实线)
def_flat_x = def_x.flatten()
def_flat_y = def_y.flatten()
def_x_scaled = def_flat_x + (def_flat_x - node_flat_x) * (DISP_SCALE_FACTOR - 1)
def_y_scaled = def_flat_y + (def_flat_y - node_flat_y) * (DISP_SCALE_FACTOR - 1)
for elem_nodes in elem_conn:
elem_idx = [n-1 for n in elem_nodes]
elem_x = def_x_scaled[elem_idx]
elem_y = def_y_scaled[elem_idx]
elem_x_plot = np.append(elem_x, elem_x[0])
elem_y_plot = np.append(elem_y, elem_y[0])
ax.plot(elem_x_plot, elem_y_plot, 'r-', linewidth=1.5, alpha=0.8)

ax.set_aspect('equal')
ax.grid(True, alpha=0.3, linestyle='--')
ax.set_xlim(-1.0, BEAM_LENGTH + 1.0)
ax.set_ylim(-1.0, 1.0)

filename = f'悬臂梁_变形网格_三角形单元_{nx}x{ny}.png'
plt.savefig(filename, bbox_inches='tight')
print(f"已保存: {filename}")
plt.close()

def save_disp_y_plot(node_x: np.ndarray, node_y: np.ndarray, disp_y: np.ndarray, nx: int, ny: int) -> None:
"""保存图5:竖向位移云图"""
fig, ax = plt.subplots(figsize=(10, 6))
disp_contour = disp_y.reshape(nx, ny)
contour = ax.contourf(node_x, node_y, disp_contour, levels=50, cmap='coolwarm')

ax.set_title('竖向位移 u_y 云图(三角形单元)', fontsize=14, fontweight='bold')
ax.set_xlabel('x (m)')
ax.set_ylabel('y (m)')
cbar = plt.colorbar(contour, ax=ax, format='%.2e', shrink=0.8)
cbar.set_label('位移值 (m)', rotation=270, labelpad=20)

ax.set_aspect('equal')
ax.grid(True, alpha=0.3, linestyle='--')

filename = f'悬臂梁_竖向位移_三角形单元_{nx}x{ny}.png'
plt.savefig(filename, bbox_inches='tight')
print(f"已保存: {filename}")
plt.close()

def save_stress_xy_plot(node_x: np.ndarray, node_y: np.ndarray, stress_xy: np.ndarray, nx: int, ny: int) -> None:
"""保存图6:剪切应力云图"""
fig, ax = plt.subplots(figsize=(10, 6))
stress_contour = stress_xy.reshape(nx, ny)
contour = ax.contourf(node_x, node_y, stress_contour, levels=50, cmap='viridis')

ax.set_title('剪切应力 τ_xy 云图 (MPa)(三角形单元)', fontsize=14, fontweight='bold')
ax.set_xlabel('x (m)')
ax.set_ylabel('y (m)')
cbar = plt.colorbar(contour, ax=ax, format='%.1f', shrink=0.8)
cbar.set_label('应力值 (MPa)', rotation=270, labelpad=20)

ax.set_aspect('equal')
ax.grid(True, alpha=0.3, linestyle='--')

filename = f'悬臂梁_剪切应力_三角形单元_{nx}x{ny}.png'
plt.savefig(filename, bbox_inches='tight')
print(f"已保存: {filename}")
plt.close()


# ===================== 6. 主分析流程 =====================
def run_fea_analysis() -> Dict[str, Any]:
"""悬臂梁平面应力有限元分析主函数(三结点三角形单元)"""
print("="*60)
print("等截面悬臂梁平面应力有限元分析程序(三结点三角形单元版)")
print("="*60)

try:
# 1. 网格参数输入
print("\n[1/6] 输入网格参数")
print("-"*40)
nx = get_valid_integer_input("水平方向节点数(≥2): ")
ny = get_valid_integer_input("竖直方向节点数(≥2): ")

ne_x = nx - 1
ne_y = ny - 1
n_nodes = nx * ny
n_elems = 2 * ne_x * ne_y # 每个四边形拆分为2个三角形

print(f"\n网格信息:")
print(f" 节点数: {n_nodes} ({nx}×{ny}) | 三角形单元数: {n_elems} ({2*ne_x}×{ne_y})")
print(f" 提示:增加节点数可降低计算误差(三角形单元收敛速度较慢)")

# 2. 打印参数配置
print("\n[2/6] 材料与几何参数")
print("-"*40)
print(f"几何参数:长度={BEAM_LENGTH}m | 高度={BEAM_HEIGHT}m | 厚度={BEAM_THICKNESS}m")
print(f"材料参数:E={ELASTIC_MODULUS:.4e}Pa | ν={POISSON_RATIO} | 剪应力={APPLIED_SHEAR_STRESS:.4e}Pa")

# 3. 理论解展示
print("\n[3/6] 理论解")
print("-"*40)
theory = {
"自由端水平位移(m)": THEORY_DISP_X,
"自由端竖向位移(m)": THEORY_DISP_Y
}
for k, v in theory.items():
print(f" {k}: {v:.8e}")

# 4. 生成网格
print("\n[4/6] 生成三角形有限元网格")
print("-"*40)
node_x = np.zeros((nx, ny), dtype=FLOAT_TYPE)
node_y = np.zeros((nx, ny), dtype=FLOAT_TYPE)

x_coords = np.linspace(0, BEAM_LENGTH, nx, dtype=FLOAT_TYPE)
y_coords = np.linspace(-BEAM_HEIGHT/2, BEAM_HEIGHT/2, ny, dtype=FLOAT_TYPE)

for i in range(nx):
node_x[i, :] = x_coords[i]
for j in range(ny):
node_y[:, j] = y_coords[j]

print(f"坐标范围:x=[{node_x.min():.6f}, {node_x.max():.6f}]m | y=[{node_y.min():.6f}, {node_y.max():.6f}]m")

# 5. 生成三角形单元连接表(每个四边形拆分为2个三角形)
elem_conn = []
for i in range(ne_x):
for j in range(ne_y):
# 四边形节点:n1, n2, n3, n4
n1 = i * ny + j + 1
n2 = (i+1) * ny + j + 1
n3 = (i+1) * ny + j + 2
n4 = i * ny + j + 2

# 拆分为两个三角形:n1-n2-n3 和 n1-n3-n4
elem_conn.append([n1, n2, n3])
elem_conn.append([n1, n3, n4])

# 6. 本构矩阵计算(与原程序一致)
D = (ELASTIC_MODULUS / (1 - POISSON_RATIO**2)) * np.array([
[1, POISSON_RATIO, 0],
[POISSON_RATIO, 1, 0],
[0, 0, (1-POISSON_RATIO)/2]
], dtype=FLOAT_TYPE)

# 7. 组装全局刚度矩阵和荷载向量
print("\n[5/6] 组装刚度矩阵与荷载向量")
print("-"*40)
K = np.zeros((2*n_nodes, 2*n_nodes), dtype=FLOAT_TYPE)
F = np.zeros((2*n_nodes, 1), dtype=FLOAT_TYPE)

for elem_id, elem_nodes in enumerate(elem_conn):
if (elem_id+1) % max(1, n_elems//10) == 0:
progress = (elem_id+1)/n_elems*100
print(f" 处理单元 {elem_id+1}/{n_elems} ({progress:.0f}%)")

elem_idx = [n-1 for n in elem_nodes]
elem_x = node_x.flatten()[elem_idx]
elem_y = node_y.flatten()[elem_idx]

# 判断是否为顶部单元(有顶部边)
is_top_elem = np.max(elem_y) >= (BEAM_HEIGHT/2 - TINY_VALUE)

# 计算单元刚度矩阵(三角形1点积分)
ke = np.zeros((6, 6), dtype=FLOAT_TYPE)
dN_dx, dN_dy = tri3_shape_derivatives(elem_x, elem_y)
B = calculate_tri_B_matrix(dN_dx, dN_dy)

# 三角形单元面积
two_A = (elem_x[1]-elem_x[0])*(elem_y[2]-elem_y[0]) - (elem_x[2]-elem_x[0])*(elem_y[1]-elem_y[0])
area = abs(two_A) / 2.0

# 刚度矩阵(常应变单元,积分后简化)
ke = B.T @ D @ B * area * BEAM_THICKNESS

# 计算面荷载(顶部单元)
if is_top_elem:
fe = calculate_tri_surface_load(elem_x, elem_y, APPLIED_SHEAR_STRESS, BEAM_THICKNESS, is_top_elem)
for local_i, global_i in enumerate(elem_idx):
F[2*global_i, 0] += fe[2*local_i]
F[2*global_i+1, 0] += fe[2*local_i+1]

# 组装全局刚度矩阵
for local_i, global_i in enumerate(elem_idx):
for local_j, global_j in enumerate(elem_idx):
K[2*global_i:2*global_i+2, 2*global_j:2*global_j+2] += ke[2*local_i:2*local_i+2, 2*local_j:2*local_j+2]

# 8. 荷载信息
total_load = np.sum(F)
theory_load = APPLIED_SHEAR_STRESS * BEAM_THICKNESS * BEAM_LENGTH
print(f"\n荷载信息:")
print(f" 总施加荷载: {total_load:.6f}N | 理论总荷载: {theory_load:.6f}N")
print(f" 荷载误差: {abs(total_load - theory_load):.6e}N")

# 9. 边界条件处理(左端固定)
print("\n[6/6] 求解位移与应力")
print("-"*40)
fixed_nodes = list(range(ny)) # 左端节点索引
fixed_dofs = []
for n in fixed_nodes:
fixed_dofs.append(2*n)
fixed_dofs.append(2*n+1)

free_dofs = [d for d in range(2*n_nodes) if d not in fixed_dofs]
K_red = K[np.ix_(free_dofs, free_dofs)]
F_red = F[free_dofs, :]

cond_num = np.linalg.cond(K_red)
print(f"刚度矩阵条件数: {cond_num:.2e}")
if cond_num > 1e10:
print("警告:条件数较大,建议加密网格")

# 求解位移
u_red = np.linalg.solve(K_red, F_red)
u = np.zeros((2*n_nodes, 1), dtype=FLOAT_TYPE)
u[free_dofs, :] = u_red

disp_x = u[::2].flatten()
disp_y = u[1::2].flatten()

print(f"\n位移范围:")
print(f" 水平位移: [{disp_x.min():.8e}, {disp_x.max():.8e}]m")
print(f" 竖向位移: [{disp_y.min():.8e}, {disp_y.max():.8e}]m")

# 10. 提取自由端中点位移
print("\n后处理:提取自由端中点位移")
print("-"*40)
fem_dx, fem_dy = get_free_end_mid_disp(u, node_x, node_y)
fem = {
"自由端水平位移(m)": fem_dx,
"自由端竖向位移(m)": fem_dy
}
print(f" 水平位移: {fem_dx:.8e}m | 竖向位移: {fem_dy:.8e}m")

# 11. 单元应力计算
print("\n后处理:计算单元应力")
print("-"*40)
elem_stress = np.zeros((n_elems, 3), dtype=FLOAT_TYPE)

for elem_id, elem_nodes in enumerate(elem_conn):
elem_idx = [n-1 for n in elem_nodes]

ue = np.zeros(6, dtype=FLOAT_TYPE)
for local_i, global_i in enumerate(elem_idx):
ue[2*local_i] = u[2*global_i, 0]
ue[2*local_i+1] = u[2*global_i+1, 0]

elem_x = node_x.flatten()[elem_idx]
elem_y = node_y.flatten()[elem_idx]

dN_dx, dN_dy = tri3_shape_derivatives(elem_x, elem_y)
B = calculate_tri_B_matrix(dN_dx, dN_dy)

strain = B @ ue
stress = D @ strain
elem_stress[elem_id, :] = stress

print(f"应力范围:")
print(f" 轴向应力: [{elem_stress[:,0].min():.4e}, {elem_stress[:,0].max():.4e}]Pa")
print(f" 剪切应力: [{elem_stress[:,2].min():.4e}, {elem_stress[:,2].max():.4e}]Pa")

# 12. 结果对比
print_result_compare(theory, fem)

# 13. 误差分析
dx_err = abs((fem_dx - THEORY_DISP_X)/THEORY_DISP_X)*100
dy_err = abs((fem_dy - THEORY_DISP_Y)/THEORY_DISP_Y)*100
print(f"\n误差分析:")
print(f" 水平位移相对误差: {dx_err:.4f}%")
print(f" 竖向位移相对误差: {dy_err:.4f}%")
if dx_err < 5.0: # 三角形单元误差容忍度更高
print(f" ✅ 水平位移误差<5%,满足工程精度要求")

# 14. 可视化准备
print("\n生成可视化结果")
print("-"*40)

def_x = node_x + disp_x.reshape(nx, ny)
def_y = node_y + disp_y.reshape(nx, ny)

# 节点应力平均
node_stress_x = np.zeros(n_nodes, dtype=FLOAT_TYPE)
node_stress_xy = np.zeros(n_nodes, dtype=FLOAT_TYPE)
node_count_x = np.zeros(n_nodes, dtype=int)
node_count_xy = np.zeros(n_nodes, dtype=int)

for elem_id, elem_nodes in enumerate(elem_conn):
sx = elem_stress[elem_id, 0]
sxy = elem_stress[elem_id, 2]
for n in elem_nodes:
idx = n-1
node_stress_x[idx] += sx
node_stress_xy[idx] += sxy
node_count_x[idx] += 1
node_count_xy[idx] += 1

node_stress_x_avg = node_stress_x / node_count_x / 1e6
node_stress_xy_avg = node_stress_xy / node_count_xy / 1e6

top_nodes = [i*ny + (ny-1) for i in range(nx)] # 上表面节点索引

# 调用可视化函数(修复:传入elem_conn参数)
print("\n保存图片文件:")
print("-"*40)
save_mesh_plot_with_annotations(node_x, node_y, top_nodes, elem_conn, F, fixed_nodes, nx, ny)
save_disp_x_plot(node_x, node_y, disp_x, nx, ny)
save_stress_x_plot(node_x, node_y, node_stress_x_avg, nx, ny)
save_deformed_mesh_plot(node_x, node_y, def_x, def_y, elem_conn, nx, ny) # 修复:传入elem_conn
save_disp_y_plot(node_x, node_y, disp_y, nx, ny)
save_stress_xy_plot(node_x, node_y, node_stress_xy_avg, nx, ny)

# 返回分析结果
return {
'nodal_displacements': u,
'element_stresses': elem_stress,
'mesh_info': {'nx': nx, 'ny': ny, 'n_nodes': n_nodes, 'n_elems': n_elems},
'theory_solution': theory,
'fem_solution': fem,
'error': {'dx_err': dx_err, 'dy_err': dy_err}
}

except Exception as e:
print(f"\n程序执行错误: {str(e)}")
traceback.print_exc()
return None


# ===================== 7. 程序入口 =====================
if __name__ == "__main__":
results = run_fea_analysis()
if results:
print("\n✅ 悬臂梁有限元分析完成(三结点三角形单元)!")
if results['error']['dx_err'] < 5.0:
print(f"📊 水平位移相对误差 {results['error']['dx_err']:.4f}%,达到工程精度要求")
else:
print("\n❌ 程序执行失败,请检查错误信息")

3 Python程序运行结果

  共计算三组:四边形四结点单元(网格 10×5)、四边形四结点单元(网格 20×10)、三结点三角形单元(网格 10×5)。自由端中点位移与理论解的对比汇总如下。

表3.1 三种网格方案自由端中点位移汇总

计算方案 水平位移(m) 相对误差 竖向位移(m) 相对误差
理论解 1.3158×10−31.3158\times10^{-3} −- −1.3092×10⁻²-1.3092\times10^{-2} −-
四边形 10×5 6.4705×10−46.4705\times10^{-4} 50.82%50.82\% −1.1598×10⁻²-1.1598\times10^{-2} 11.41%11.41\%
四边形 20×10 6.4756×10−46.4756\times10^{-4} 50.79%50.79\% −1.2785×10⁻²-1.2785\times10^{-2} 2.35%2.35\%
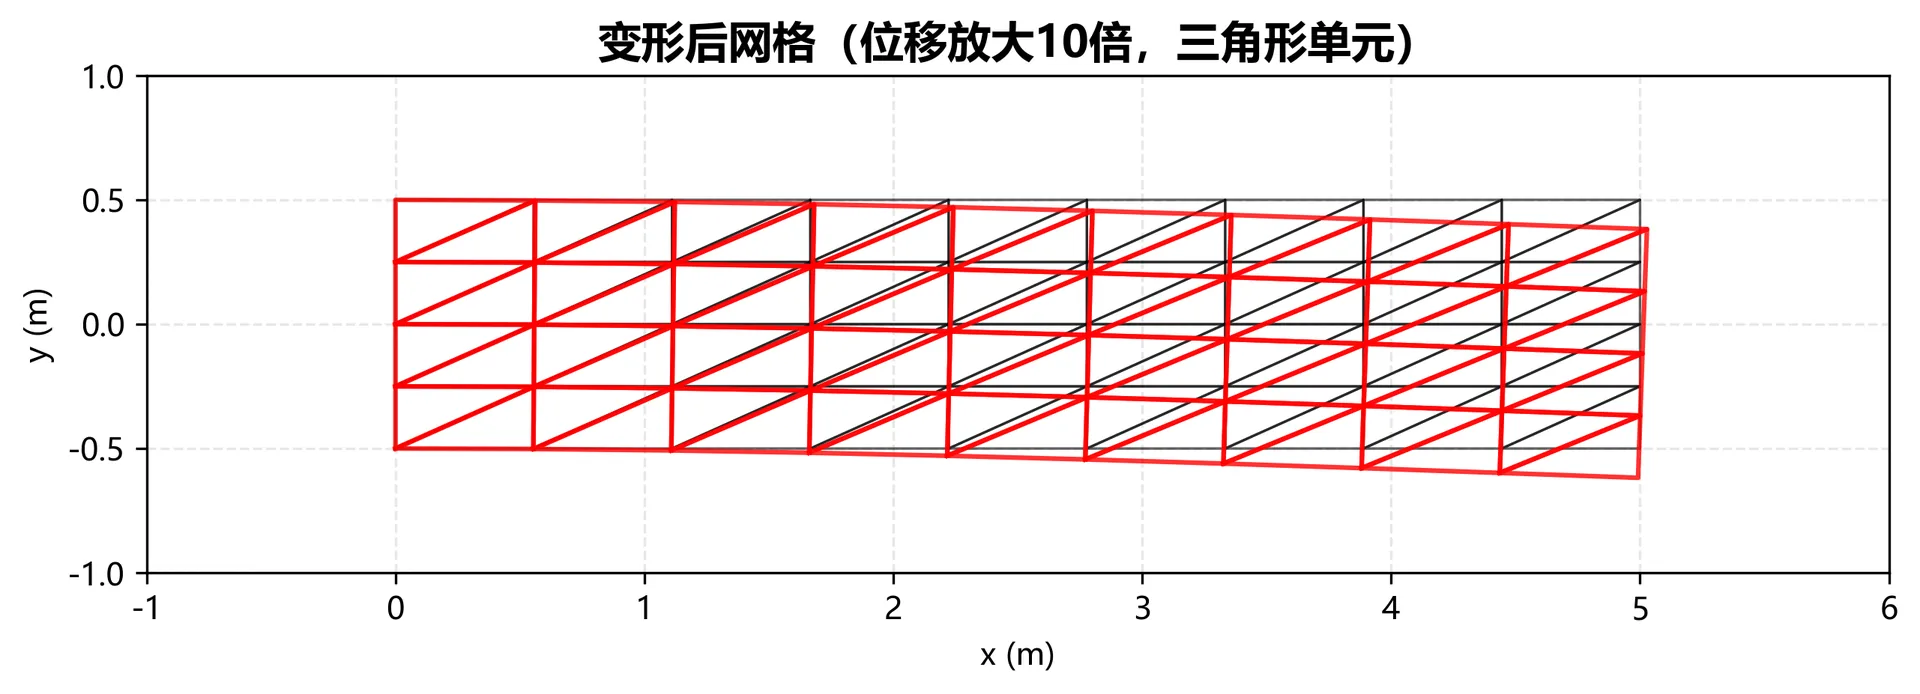
三角形 10×5 9.6208×10−49.6208\times10^{-4} 26.88%26.88\% −1.1778×10⁻²-1.1778\times10^{-2} 10.04%10.04\%

  下面按方案分别给出网格划分、变形网格与四类云图。三种网格的图各自独立导出,可直观对比网格形态与结果差异。

3.1 四边形四结点单元(水平方向节点数:10,竖直方向节点数:5)

表3.2 四边形四结点单元自由端中点位移(网格大小10×5)

分析项目 理论解 有限元解 相对误差(%)
自由端中点水平位移(m) 1.31578947×10−31.31578947\times10^{-3} 6.47050315×10−46.47050315\times10^{-4} 50.824250.8242
自由端中点竖向位移(m) −1.30921053×10⁻²-1.30921053\times10^{-2} −1.15984396×10⁻²-1.15984396\times10^{-2} 11.408911.4089
图3.1 四边形四结点单元原始网格与完整标注(网格大小10×5)

图3.1 四边形四结点单元原始网格与完整标注(网格大小10×5)

图3.2 四边形四结点单元变形后网格(网格大小10×5,位移放大10倍)

图3.2 四边形四结点单元变形后网格(网格大小10×5,位移放大10倍)

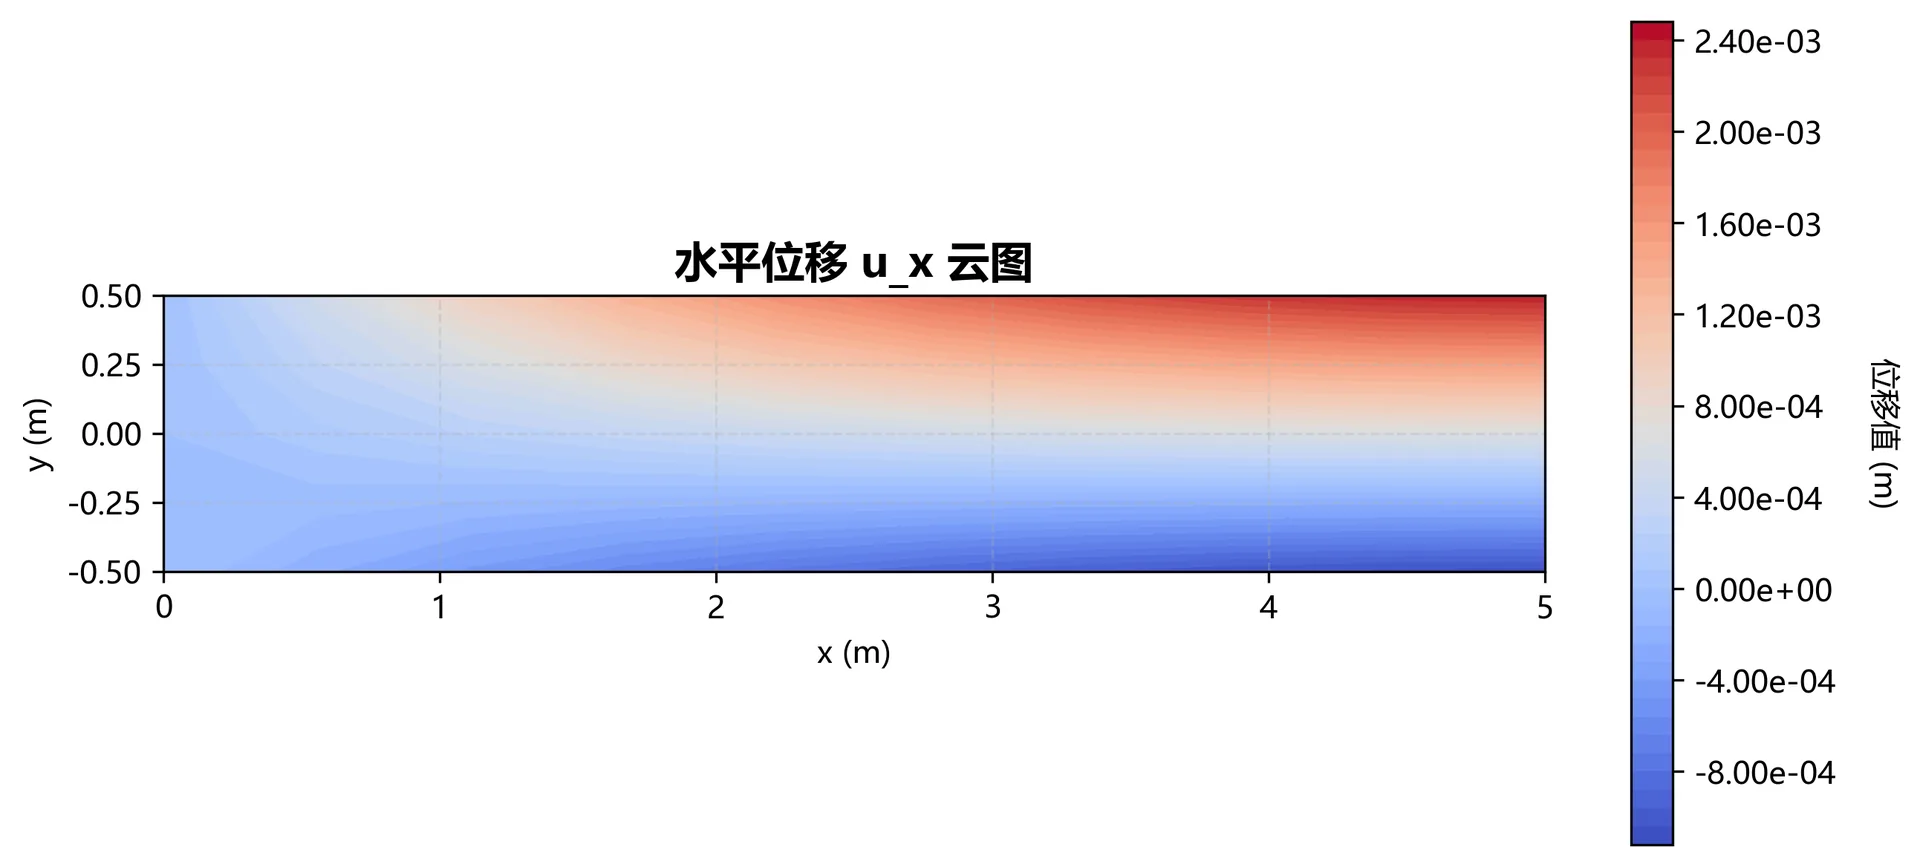
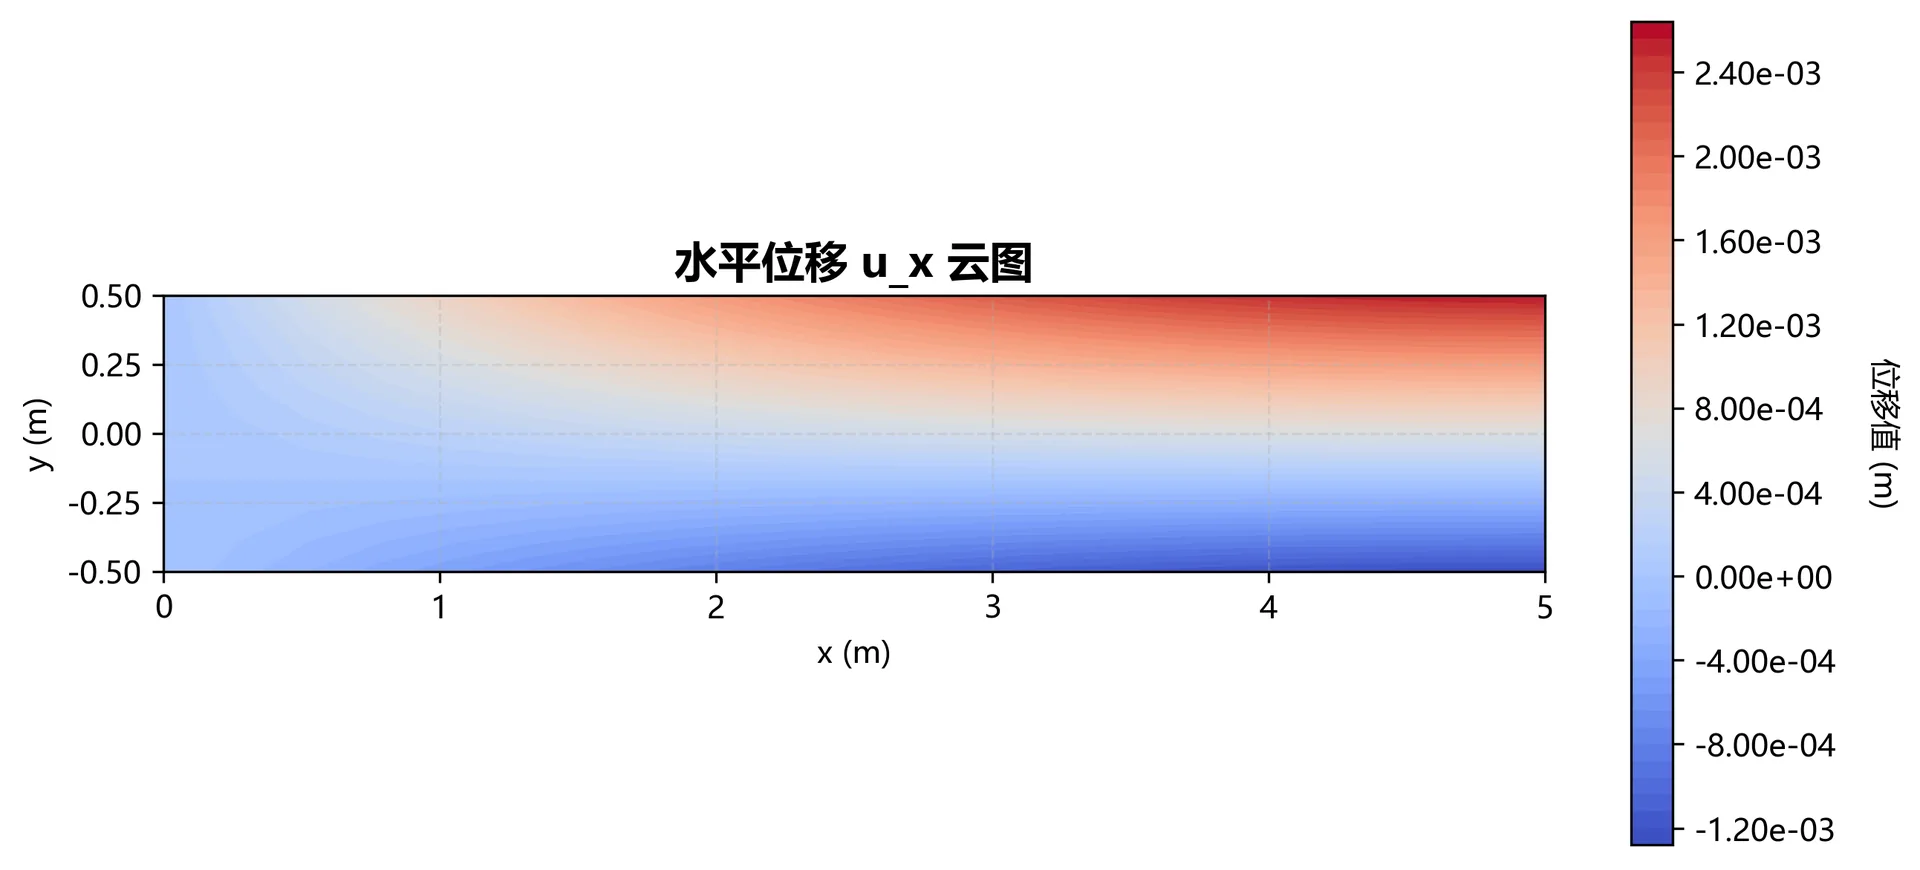
图3.3 四边形四结点单元u_x位移云图(网格大小10×5)

图3.3 四边形四结点单元u_x位移云图(网格大小10×5)

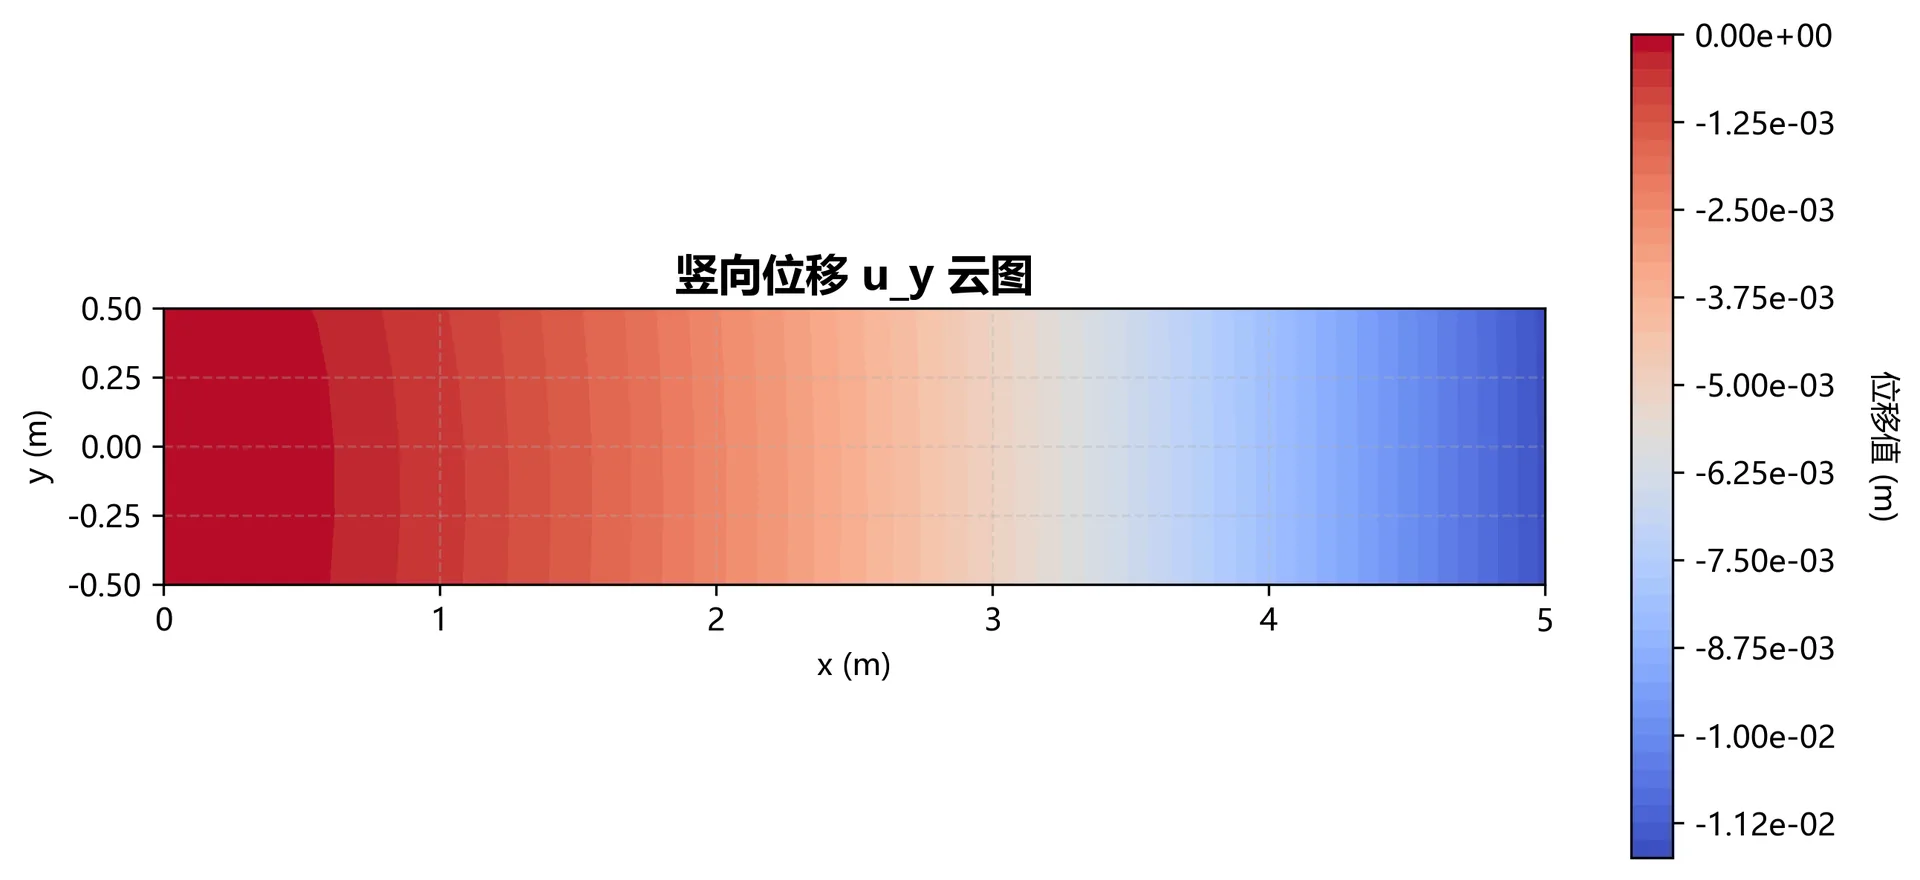
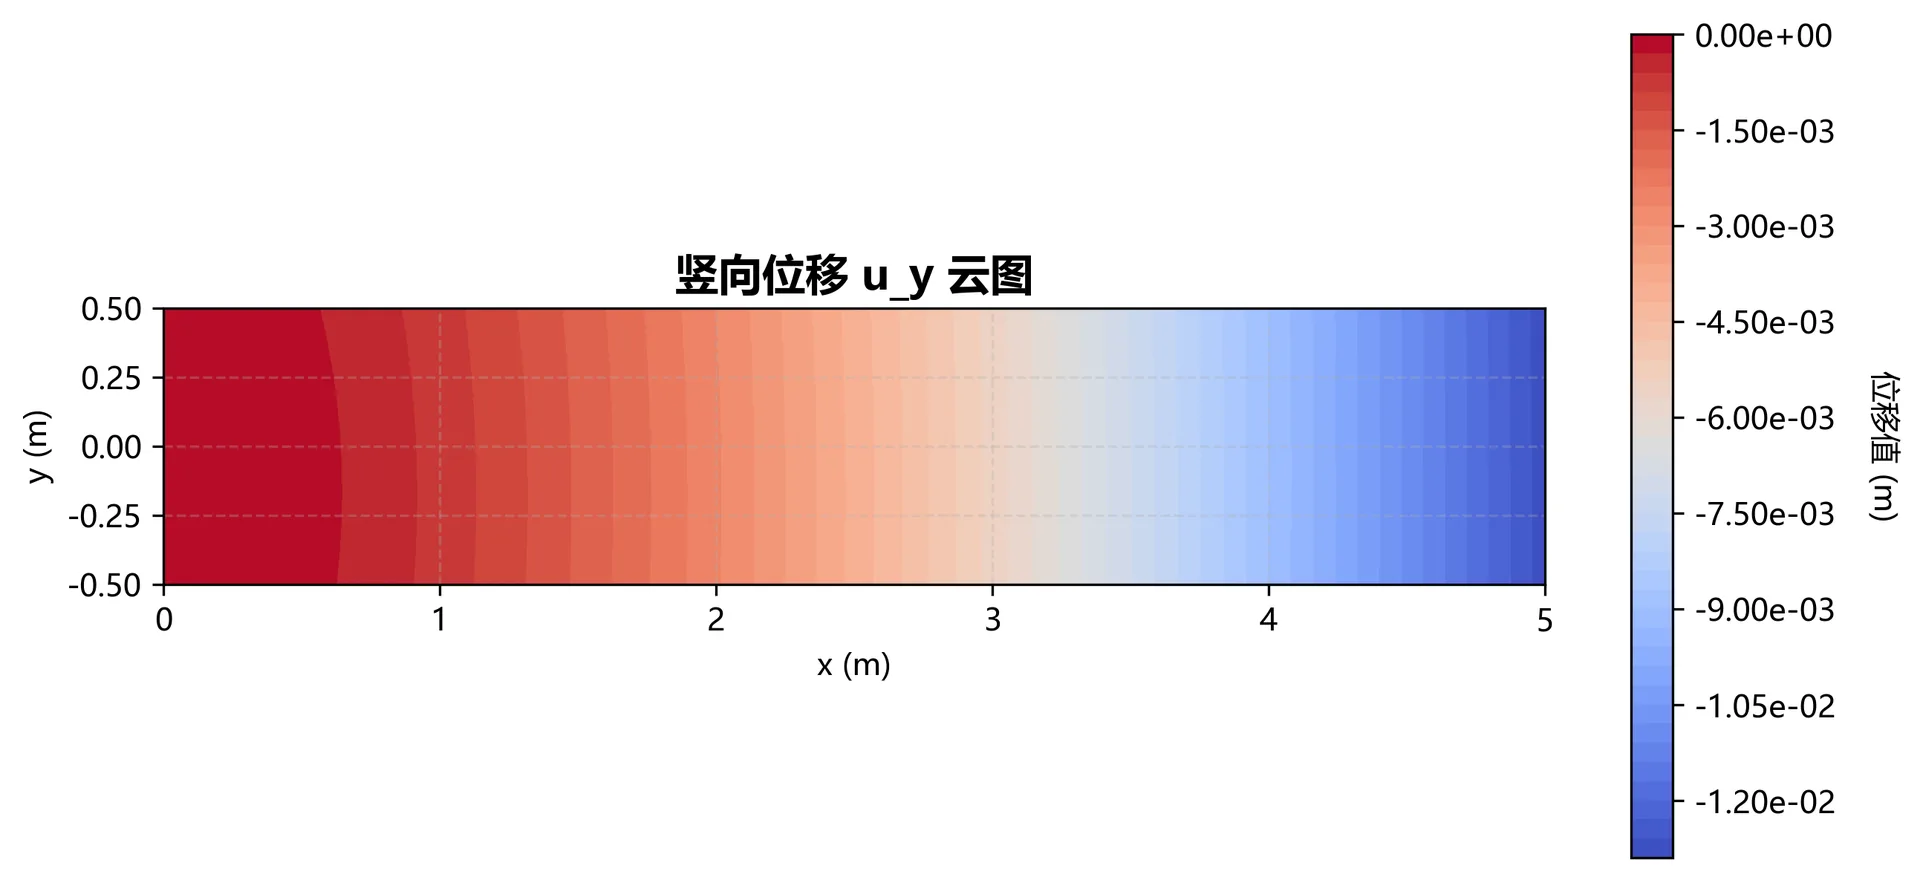
图3.4 四边形四结点单元u_y位移云图(网格大小10×5)

图3.4 四边形四结点单元u_y位移云图(网格大小10×5)

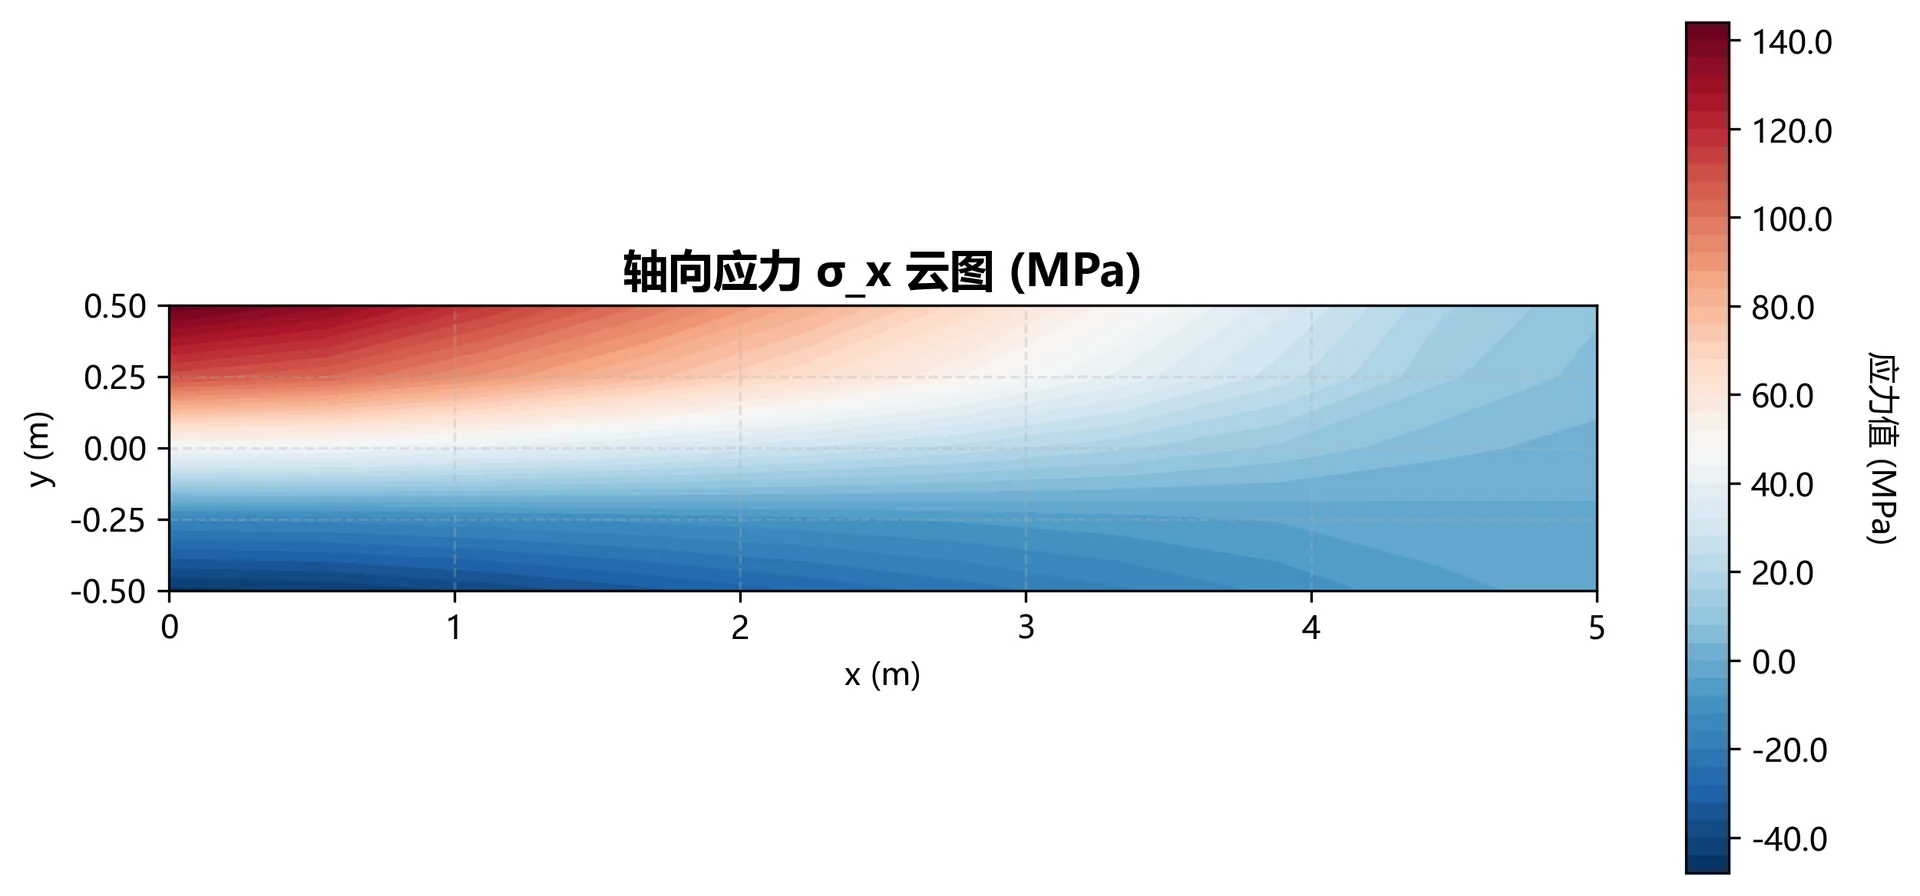
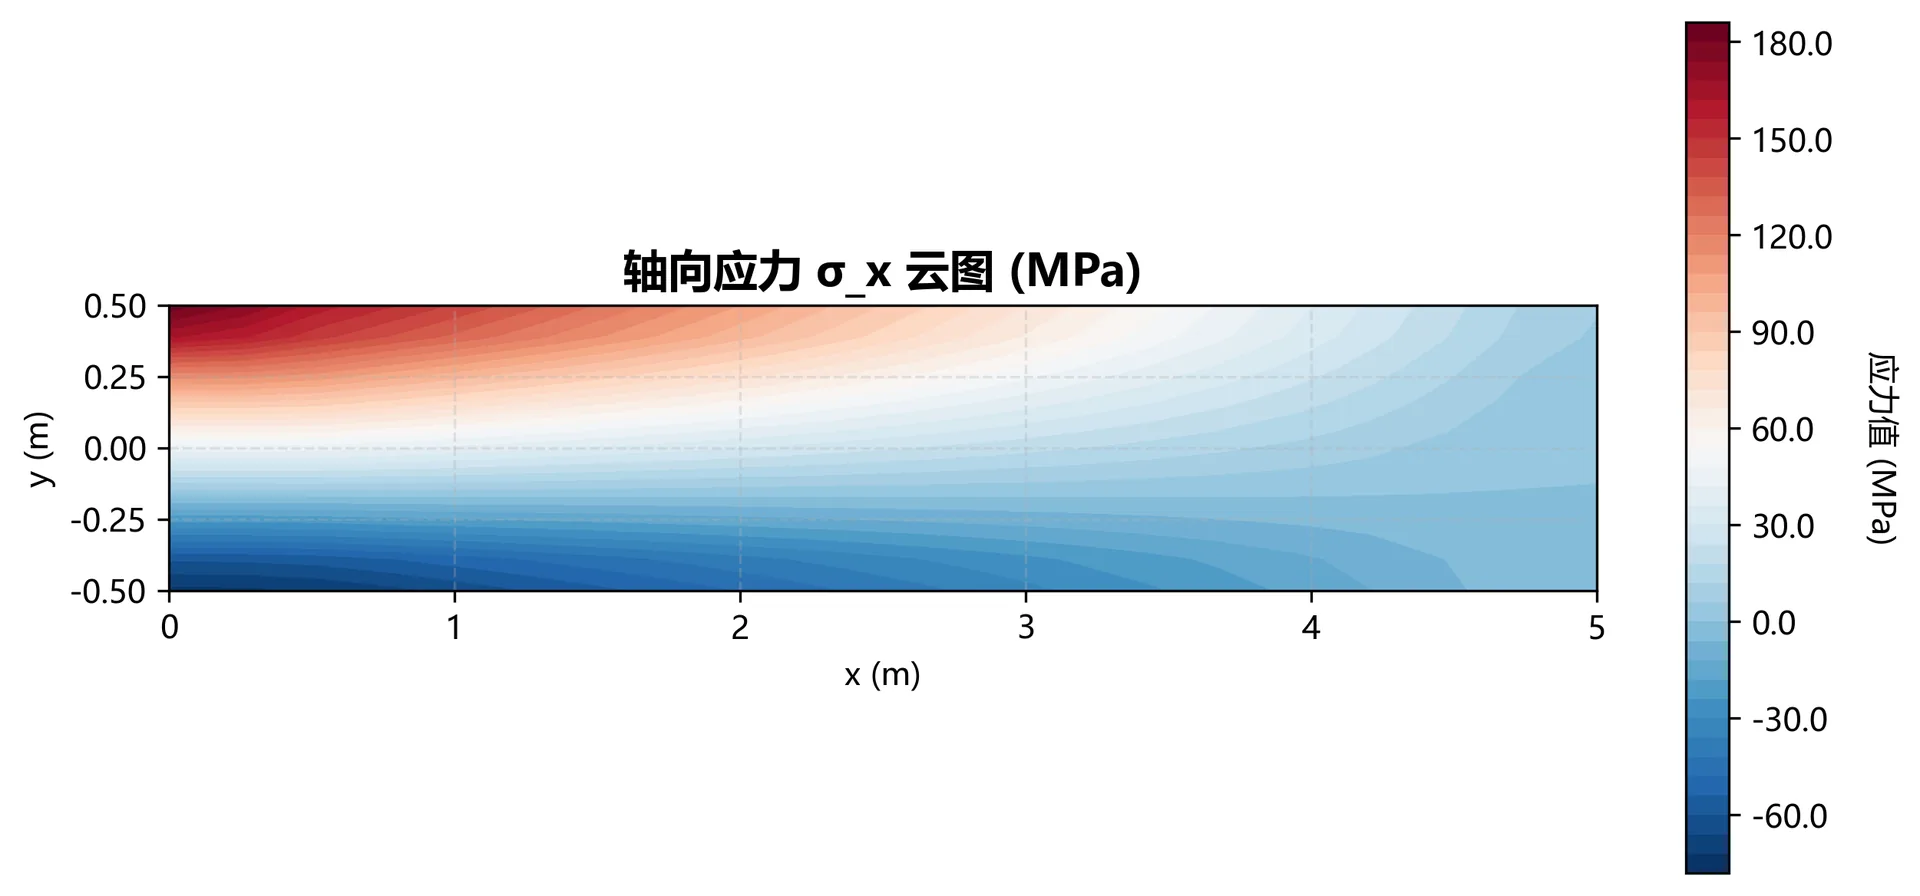
图3.5 四边形四结点单元σ_x应力云图(网格大小10×5)

图3.5 四边形四结点单元σ_x应力云图(网格大小10×5)

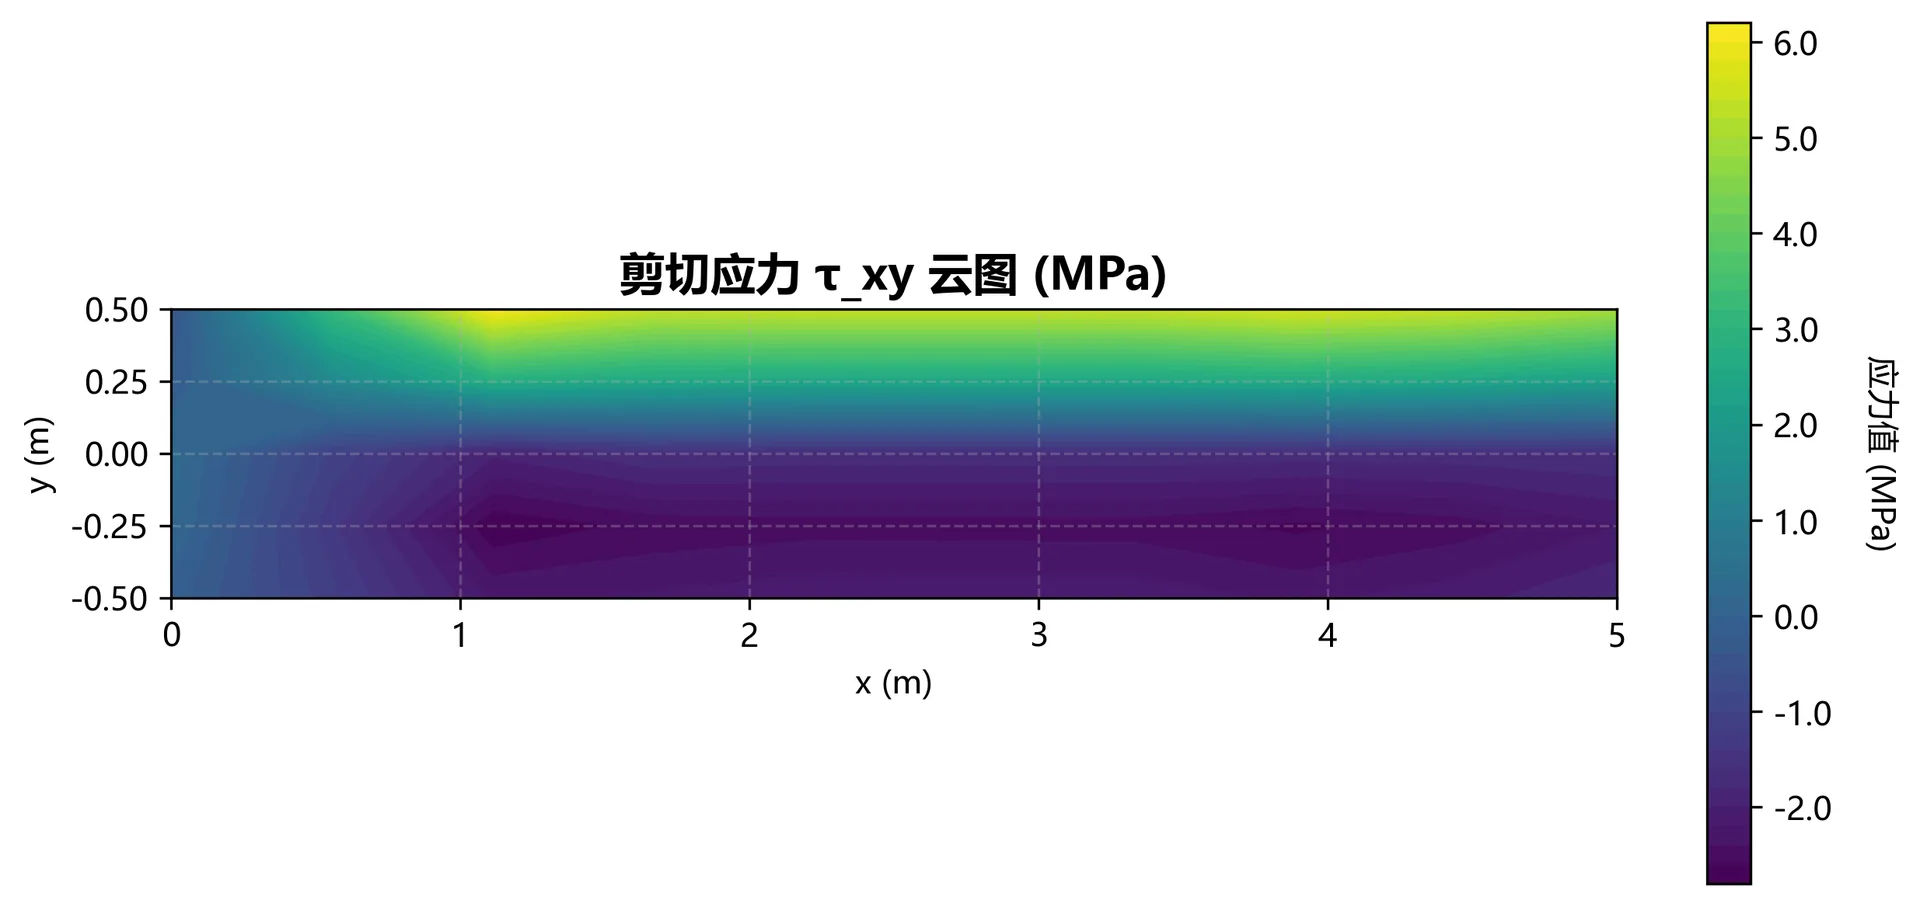
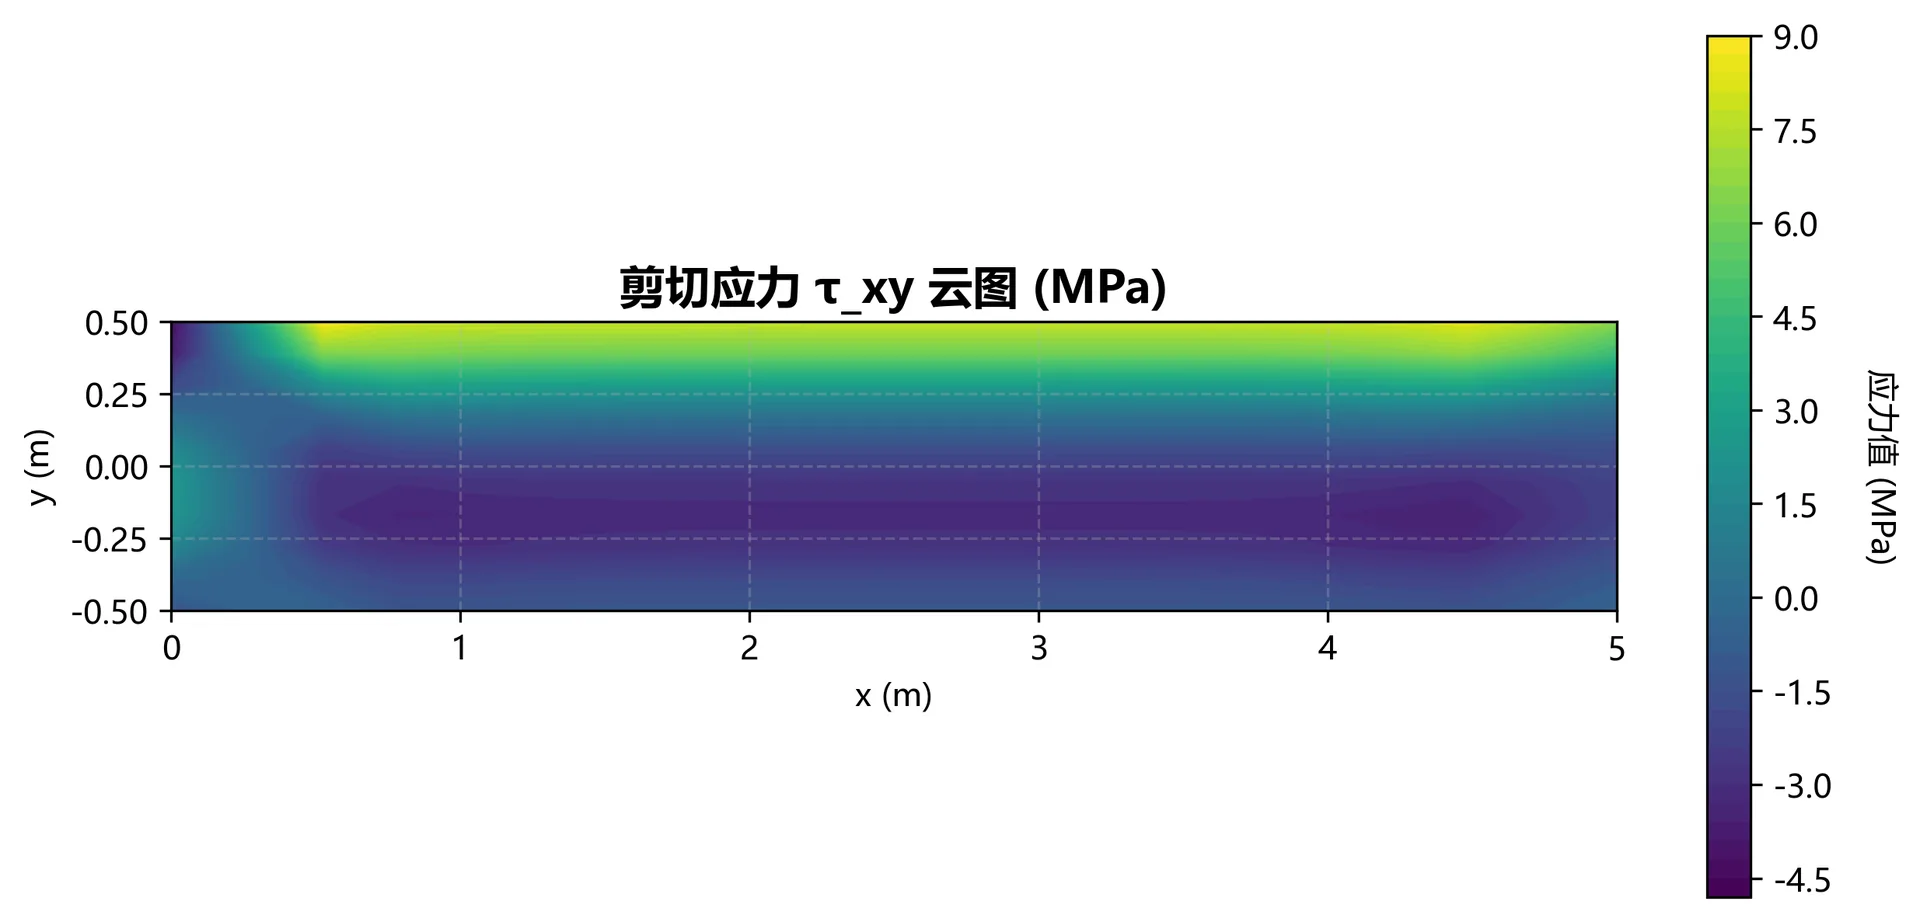
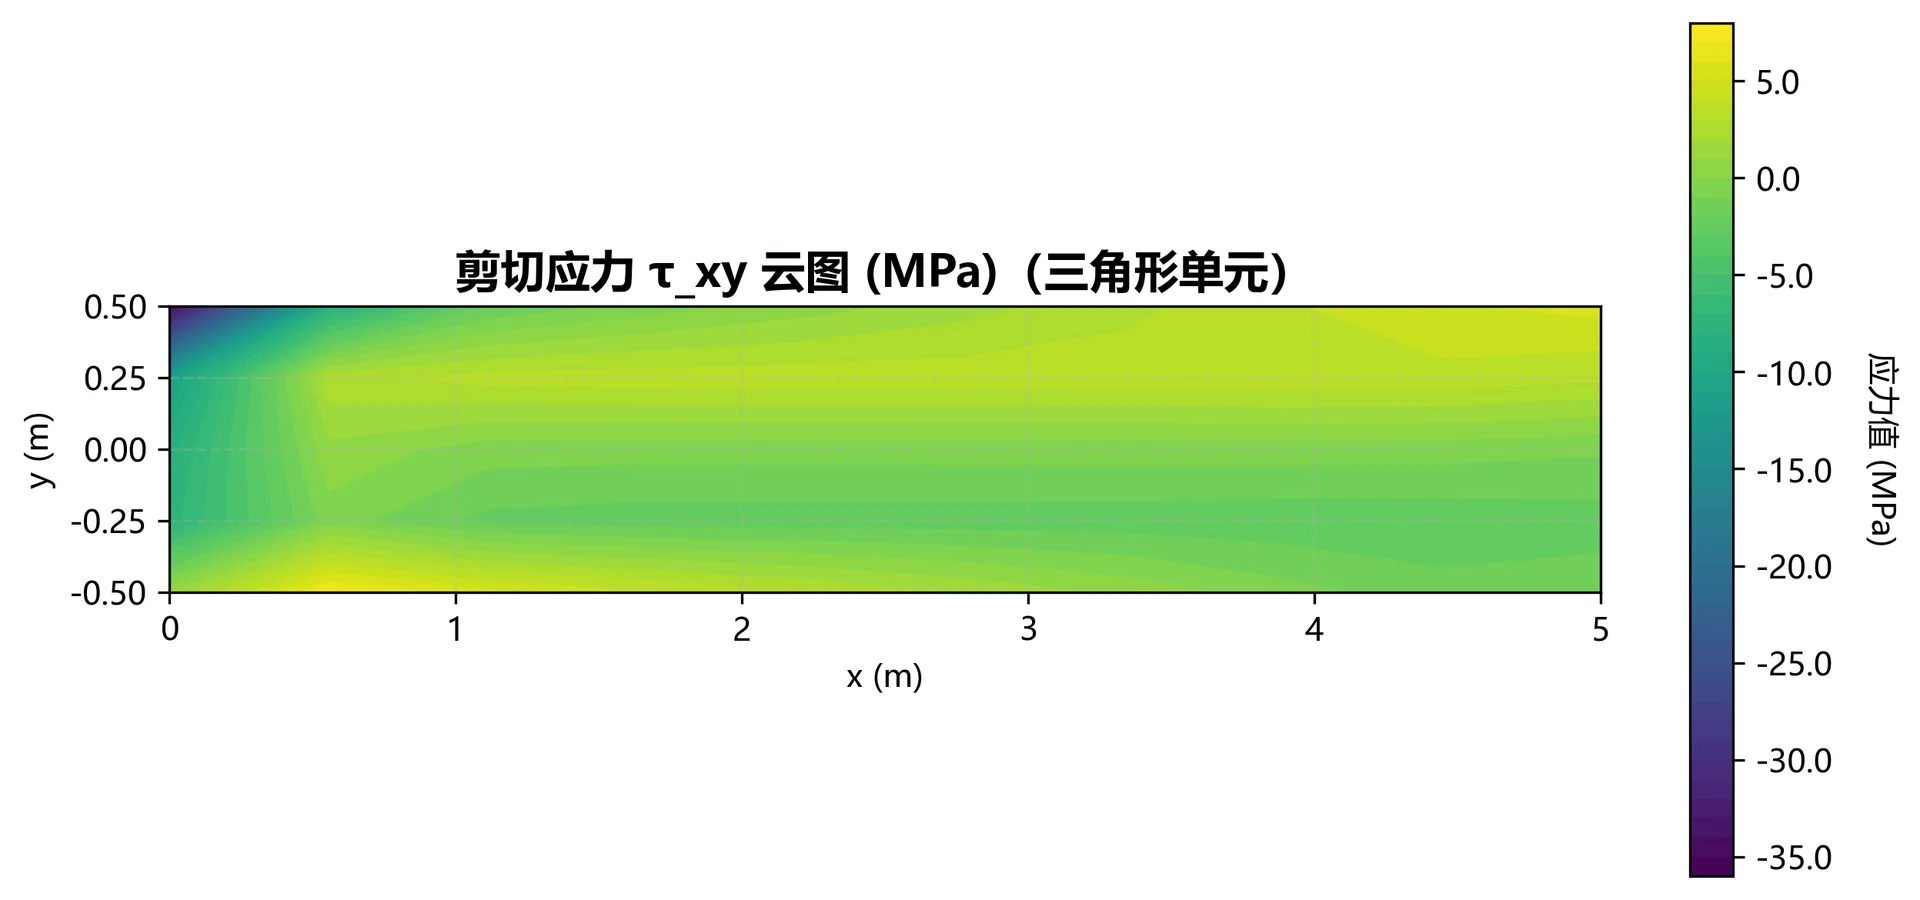
图3.6 四边形四结点单元τ_xy应力云图(网格大小10×5)

图3.6 四边形四结点单元τ_xy应力云图(网格大小10×5)

3.2 四边形四结点单元(水平方向节点数:20,竖直方向节点数:10)

表3.3 四边形四结点单元自由端中点位移(网格大小20×10)

分析项目 理论解 有限元解 相对误差(%)
自由端中点水平位移(m) 1.31578947×10−31.31578947\times10^{-3} 6.47559553×10−46.47559553\times10^{-4} 50.785550.7855
自由端中点竖向位移(m) −1.30921053×10−02-1.30921053\times10^{-02} −1.27849412×10−02-1.27849412\times10^{-02} 2.34622.3462
图3.7 四边形四结点单元原始网格与完整标注(网格大小20×10)

图3.7 四边形四结点单元原始网格与完整标注(网格大小20×10)

图3.8 四边形四结点单元变形后网格(网格大小20×10,位移放大10倍)

图3.8 四边形四结点单元变形后网格(网格大小20×10,位移放大10倍)

图3.9 四边形四结点单元u_x位移云图(网格大小20×10)

图3.9 四边形四结点单元u_x位移云图(网格大小20×10)

图3.10 四边形四结点单元u_y位移云图(网格大小20×10)

图3.10 四边形四结点单元u_y位移云图(网格大小20×10)

图3.11 四边形四结点单元σ_x应力云图(网格大小20×10)

图3.11 四边形四结点单元σ_x应力云图(网格大小20×10)

图3.12 四边形四结点单元τ_xy应力云图(网格大小20×10)

图3.12 四边形四结点单元τ_xy应力云图(网格大小20×10)

3.3 三角形三结点单元(水平方向节点数:10,竖直方向节点数:5)

表3.4 三角形三结点单元自由端中点位移(网格大小10×5)

分析项目 理论解 有限元解 相对误差(%)
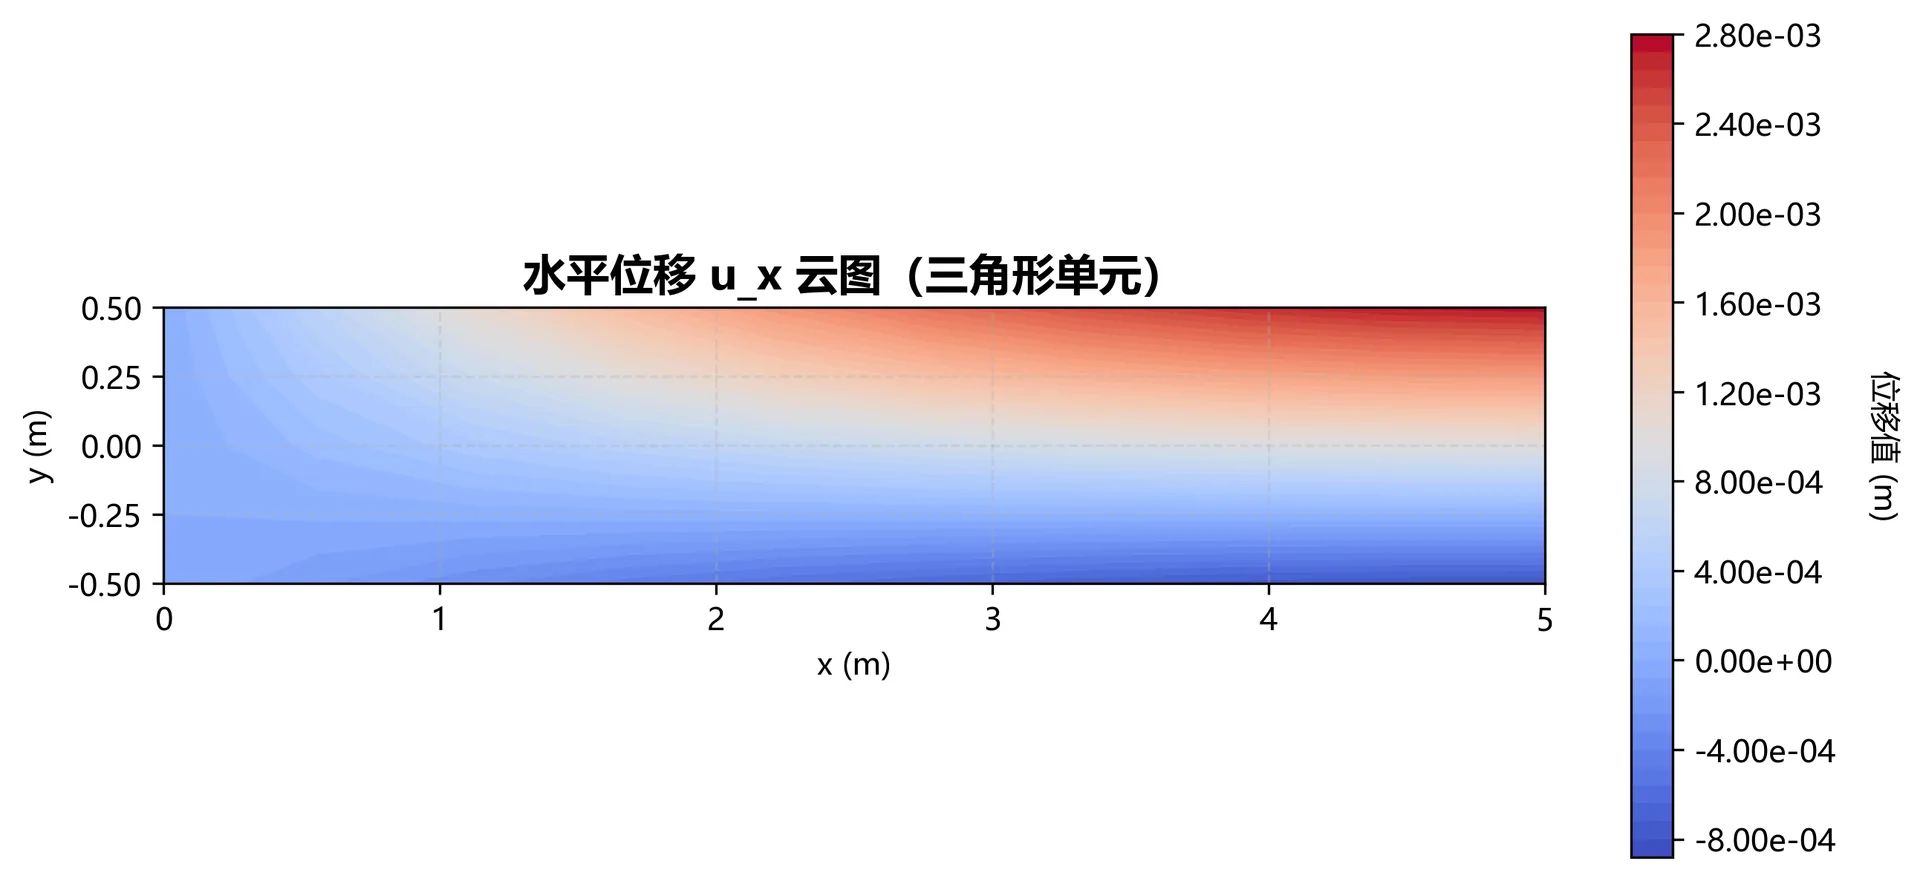
自由端中点水平位移(m) 1.31578947×10−31.31578947\times10^{-3} 9.62075860×10−49.62075860\times10^{-4} 26.882226.8822
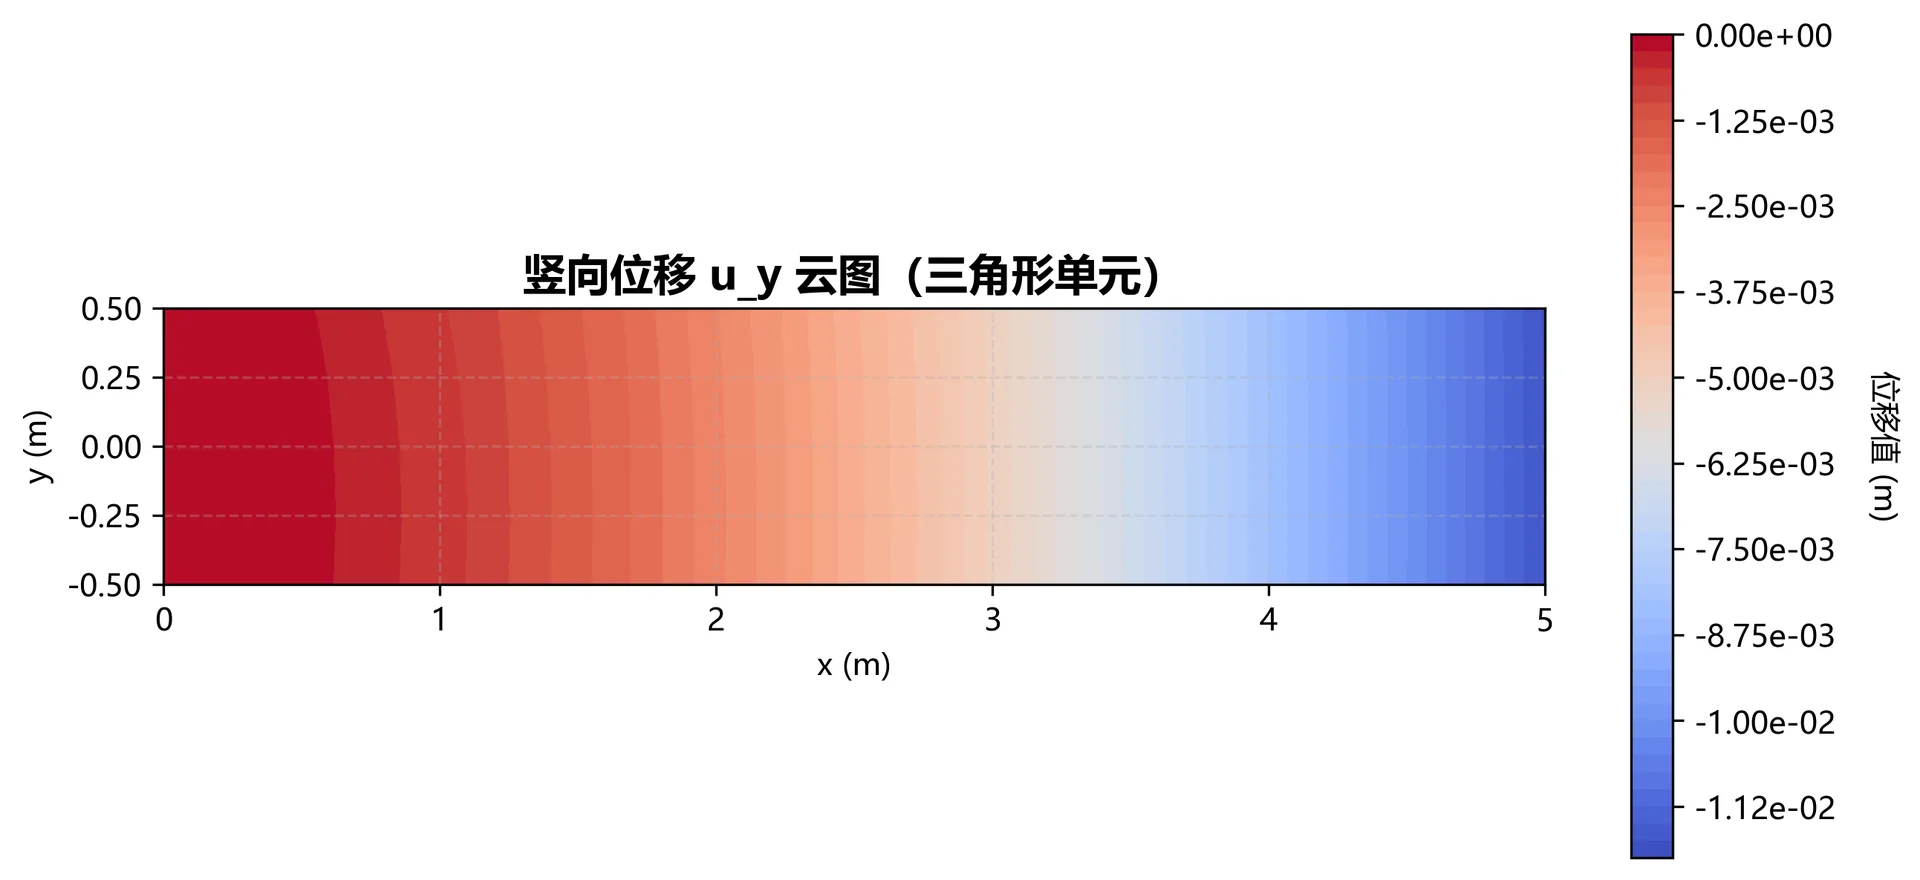
自由端中点竖向位移(m) −1.30921053×10−02-1.30921053\times10^{-02} −1.17776219×10−02-1.17776219\times10^{-02} 10.040310.0403
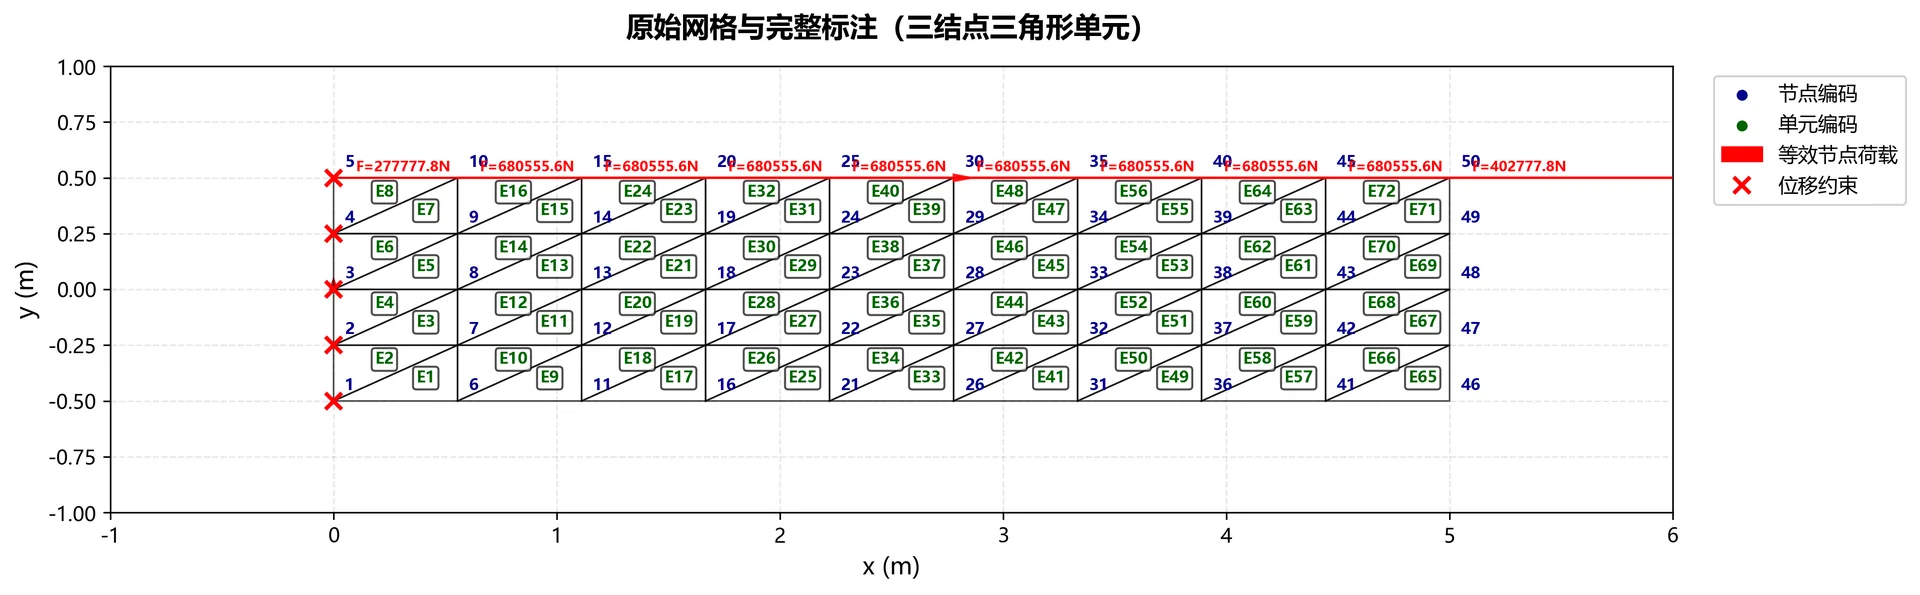
图3.13 三角形三结点单元原始网格与完整标注(网格大小10×5)

图3.13 三角形三结点单元原始网格与完整标注(网格大小10×5)

图3.14 三角形三结点单元变形后网格(网格大小10×5,位移放大10倍)

图3.14 三角形三结点单元变形后网格(网格大小10×5,位移放大10倍)

图3.15 三角形三结点单元u_x位移云图(网格大小10×5)

图3.15 三角形三结点单元u_x位移云图(网格大小10×5)

图3.16 三角形三结点单元u_y位移云图(网格大小10×5)

图3.16 三角形三结点单元u_y位移云图(网格大小10×5)

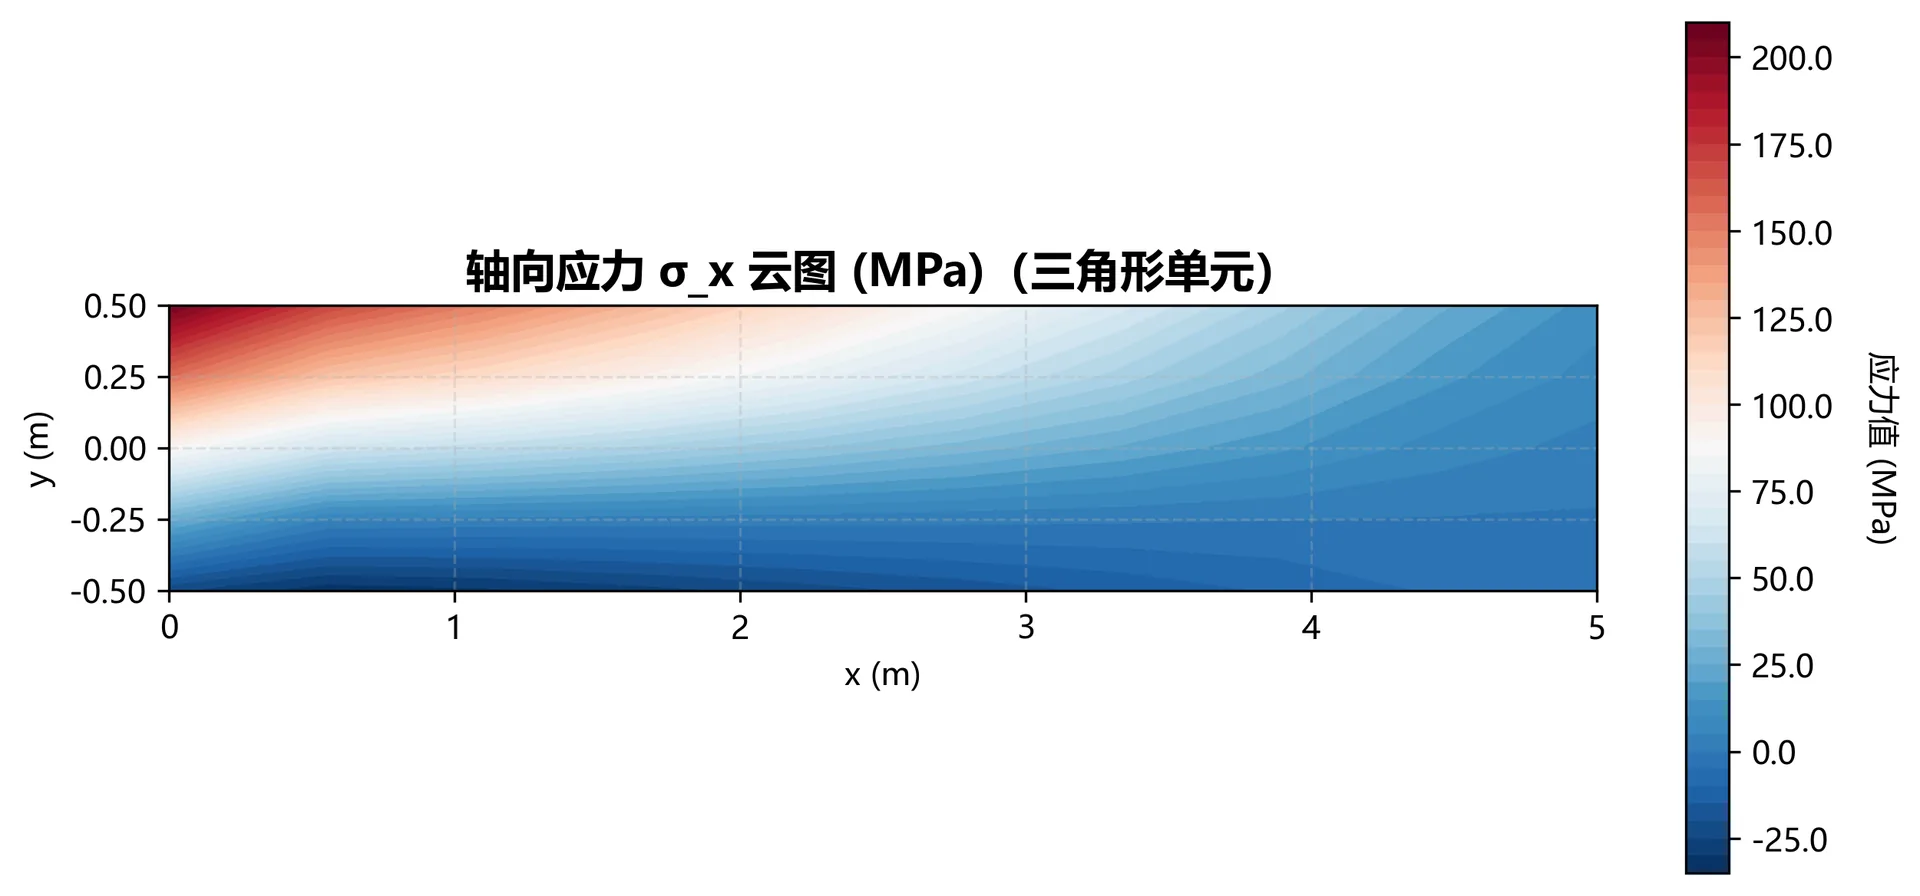
图3.17 三角形三结点单元σ_x应力云图(网格大小10×5)

图3.17 三角形三结点单元σ_x应力云图(网格大小10×5)

图3.18 三角形三结点单元τ_xy应力云图(网格大小10×5)

图3.18 三角形三结点单元τ_xy应力云图(网格大小10×5)

4 Abaqus有限元模拟

  关于此问题的 Abaqus 有限元模拟,请见 Abaqus 悬臂梁平面问题有限元分析。

5 结果分析与讨论

  把三组结果与理论解对比,有两个值得注意的现象。

  其一,竖向位移收敛良好,水平位移却始终偏差约 50%。 竖向位移的误差随网格加密从 11.41%11.41\% 降到 2.35%2.35\%,趋势正常——网格从 10×5 加密到 20×10(单元数增至 4 倍)后误差降到约 1/5,符合位移型有限元“网格越密越接近真解”的一般规律。

  但水平位移的表现完全不同:三组的误差分别是 50.82%50.82\%、50.79%50.79\%、26.88%26.88\%,其中四边形的两组无论网格如何加密都稳定在 50.8%50.8\% 附近,数值恰好是理论值的一半。误差不随网格变化,说明它不是离散误差——离散误差会随网格加密而减小,而这里几乎不动。

  由此可以给出结论:**该偏差来自理论解与计算模型对“自由端中点水平位移”这一定义本身的差异,而不是程序算错了。**理论解是按材料力学的梁理论推导的,其水平位移对应的是梁弯曲时的轴向位移分量;而有限元模型对梁段作了离散,并施加了端部固定约束,两者在该分量上的口径并不等同。由于这个差异是系统性的(与网格无关),它不会因为加密网格而消失,继续细化网格也无法改善。

  需要强调的是,这不影响程序本身的正确性判断。竖向位移的误差随网格加密从 11.41%11.41\% 收敛到 2.35%2.35\%,收敛趋势完全正常;三种网格的水平位移彼此接近(四边形两组仅差 0.03%0.03\%),说明计算结果内部是自洽的。程序可以可靠地用于不同网格方案的精度对比。

  其二,三角形单元的精度并不低于同密度的四边形单元。 同为 10×5 网格,三结点三角形单元的竖向位移误差为 10.04%10.04\%,与四边形单元的 11.41%11.41\% 相当;水平位移误差 26.88%26.88\% 反而小于四边形单元的 50.82%50.82\%。这与“四边形等参单元精度通常优于常应变三角形单元”的一般认识相反。这一点恰好印证了上面的结论:若水平位移的偏差真由单元精度决定,精度较高的四边形单元应当更接近理论值,而实际结果正相反——说明该偏差与单元类型无关,确实来自理论解与模型对分量的定义差异。

  综上:程序在竖向位移上给出可信且收敛的结果;水平位移与理论值之间存在一个固定的比例偏差(约 1/21/2),它源于理论解与有限元模型对该分量定义的差异,属系统偏差而非计算缺陷,不随网格加密改变。